Guide Instead of Teach
Provide guidance at the moment of action, so agents do not have to rely on training or memory.
Case Study
UVeye's automated drive-through systems deliver fast, consistent vehicle inspections, but they are not practical for every rental location. They require dedicated physical space, suitable site conditions, technical infrastructure, and an investment that smaller or temporary sites cannot always support. HLE extended vehicle documentation to those locations through a mobile capture experience, but the existing flow was difficult to follow, inconsistently used, and sometimes abandoned before completion.
I led the end-to-end product design for HLE, transforming an unstructured photo task into a guided 20-image inspection flow. The launched experience gave agents clear direction at every step, increased field adoption, and helped more inspections reach completion.
Every vehicle handoff creates risk.
When a rental vehicle is picked up or returned, its condition must be documented quickly and consistently. Incomplete or poor-quality evidence can lead to missed damage, disputed claims, and inconsistent decisions across locations.
At scale, the challenge grows. Agents work under time pressure and changing field conditions, while the inspection system depends on clear, correctly framed images. When image quality drops, so does the reliability of the entire process.
UVeye's fixed drive-through systems automate vehicle inspection within seconds, using high-resolution imaging, sensors, and AI to examine the exterior, underbody, and tires.
However, these systems require dedicated physical space, suitable site conditions, power and data connectivity, and installation infrastructure. For smaller branches, pop-up locations, and temporary operations, a permanent system is not always practical.
HLE was created to close this coverage gap. It brought a structured inspection workflow to the mobile device already in the agent's hand, enabling sites without a fixed scanning system to capture consistent visual evidence at every vehicle handoff.
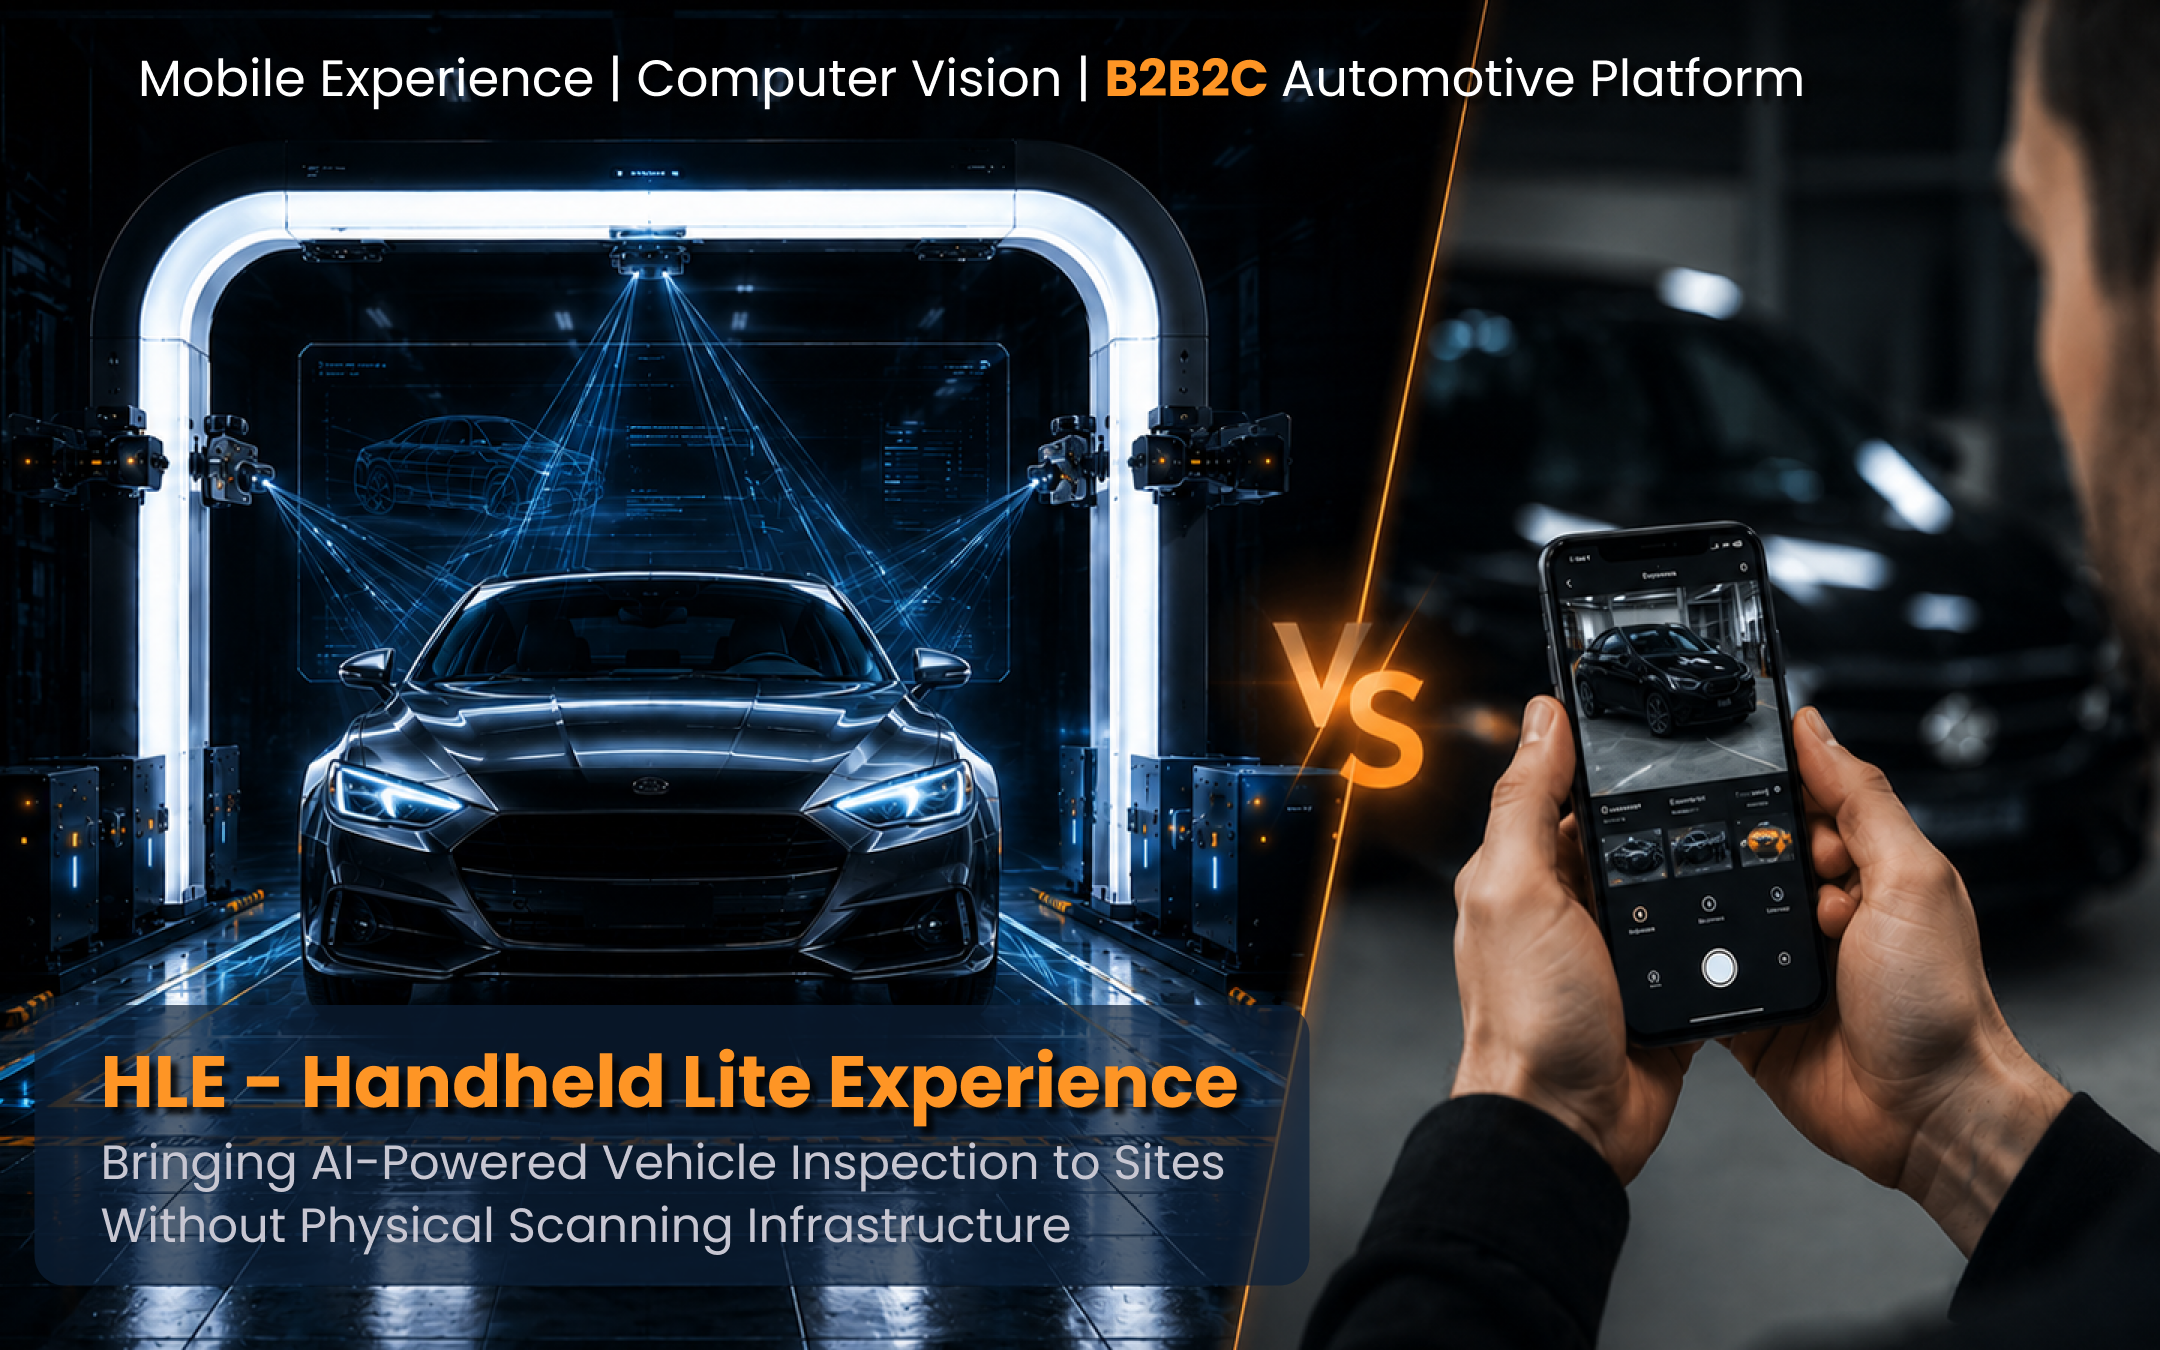
A mobile capture flow already existed, but it placed too much responsibility on the agent. Users had to determine what to capture, which photos were required, where to stand, how to frame the vehicle, and why an image had failed validation.
The workflow also depended on one-time, in-person training. When trained agents changed shifts or left the company, new staff often inherited the task without the knowledge needed to complete it correctly.
Under time pressure, the results were inconsistent. Required photos were skipped, images were captured from the wrong angle, and some inspections were abandoned before completion. When the images could not be reliably analyzed, the system could not deliver on its core promise.
This was not a problem that could be solved by improving a single screen. The entire capture journey needed clearer structure, embedded guidance, and immediate feedback.
The primary users were rental branch agents documenting vehicles during pickup and return. They were not professional photographers or vehicle inspectors. They used the product while serving customers, often in busy parking lots, direct sunlight, poorly lit garages, or rain.
They did not need more functionality. They needed a system that made the next action obvious, confirmed when a photo met the required standard, and helped them recover quickly when it did not.
This led to the central design challenge:
How might we make vehicle capture simple enough for non-expert agents while ensuring that the resulting images meet the quality requirements of an AI-powered inspection system?
The project began with an assumption that agents needed help taking better photos. Conversations with agents and observation of the existing workflow revealed a deeper problem: users did not know what the system expected from them at each stage.
They were repeatedly asking:
Where am I in the process?
Which part of the vehicle comes next?
Is the photo I just took good enough?
If it was rejected, what went wrong and what should I do next?
This wasn't a photography problem. It was an uncertainty problem.
That insight reframed the project. Instead of improving the camera interface in isolation, I needed to design a guidance system that removed uncertainty across the entire inspection journey.
Before designing the new flow, I translated the field insights into four principles that guided every interaction and tradeoff.
Provide guidance at the moment of action, so agents do not have to rely on training or memory.
Use visual examples and overlays to make the correct framing immediately understandable.
Treat mistakes as part of the workflow and always provide a clear path forward.
Design for outdoor light, changing weather, shared devices, interruptions, and time pressure - not ideal conditions.
In collaboration with the Data and Algorithms teams, I translated the system's image requirements into a 20-photo sequence: 16 vehicle angles providing full 360-degree exterior coverage, and four tire photos, one for each wheel. Together, these images provided the visual coverage required for consistent analysis and before-and-after comparison.
I transformed this sequence into a clear, navigable workflow. A persistent progress panel presented every required shot as a visual checklist, marked completed images, and showed agents exactly what to capture next.
By making the sequence visible and embedding guidance into the flow, the experience could support first-time agents without requiring a trainer to be present, while allowing experienced agents to move through the inspection efficiently.
Because one-time training could not support changing shifts and new staff over time, onboarding needed to live inside the product.
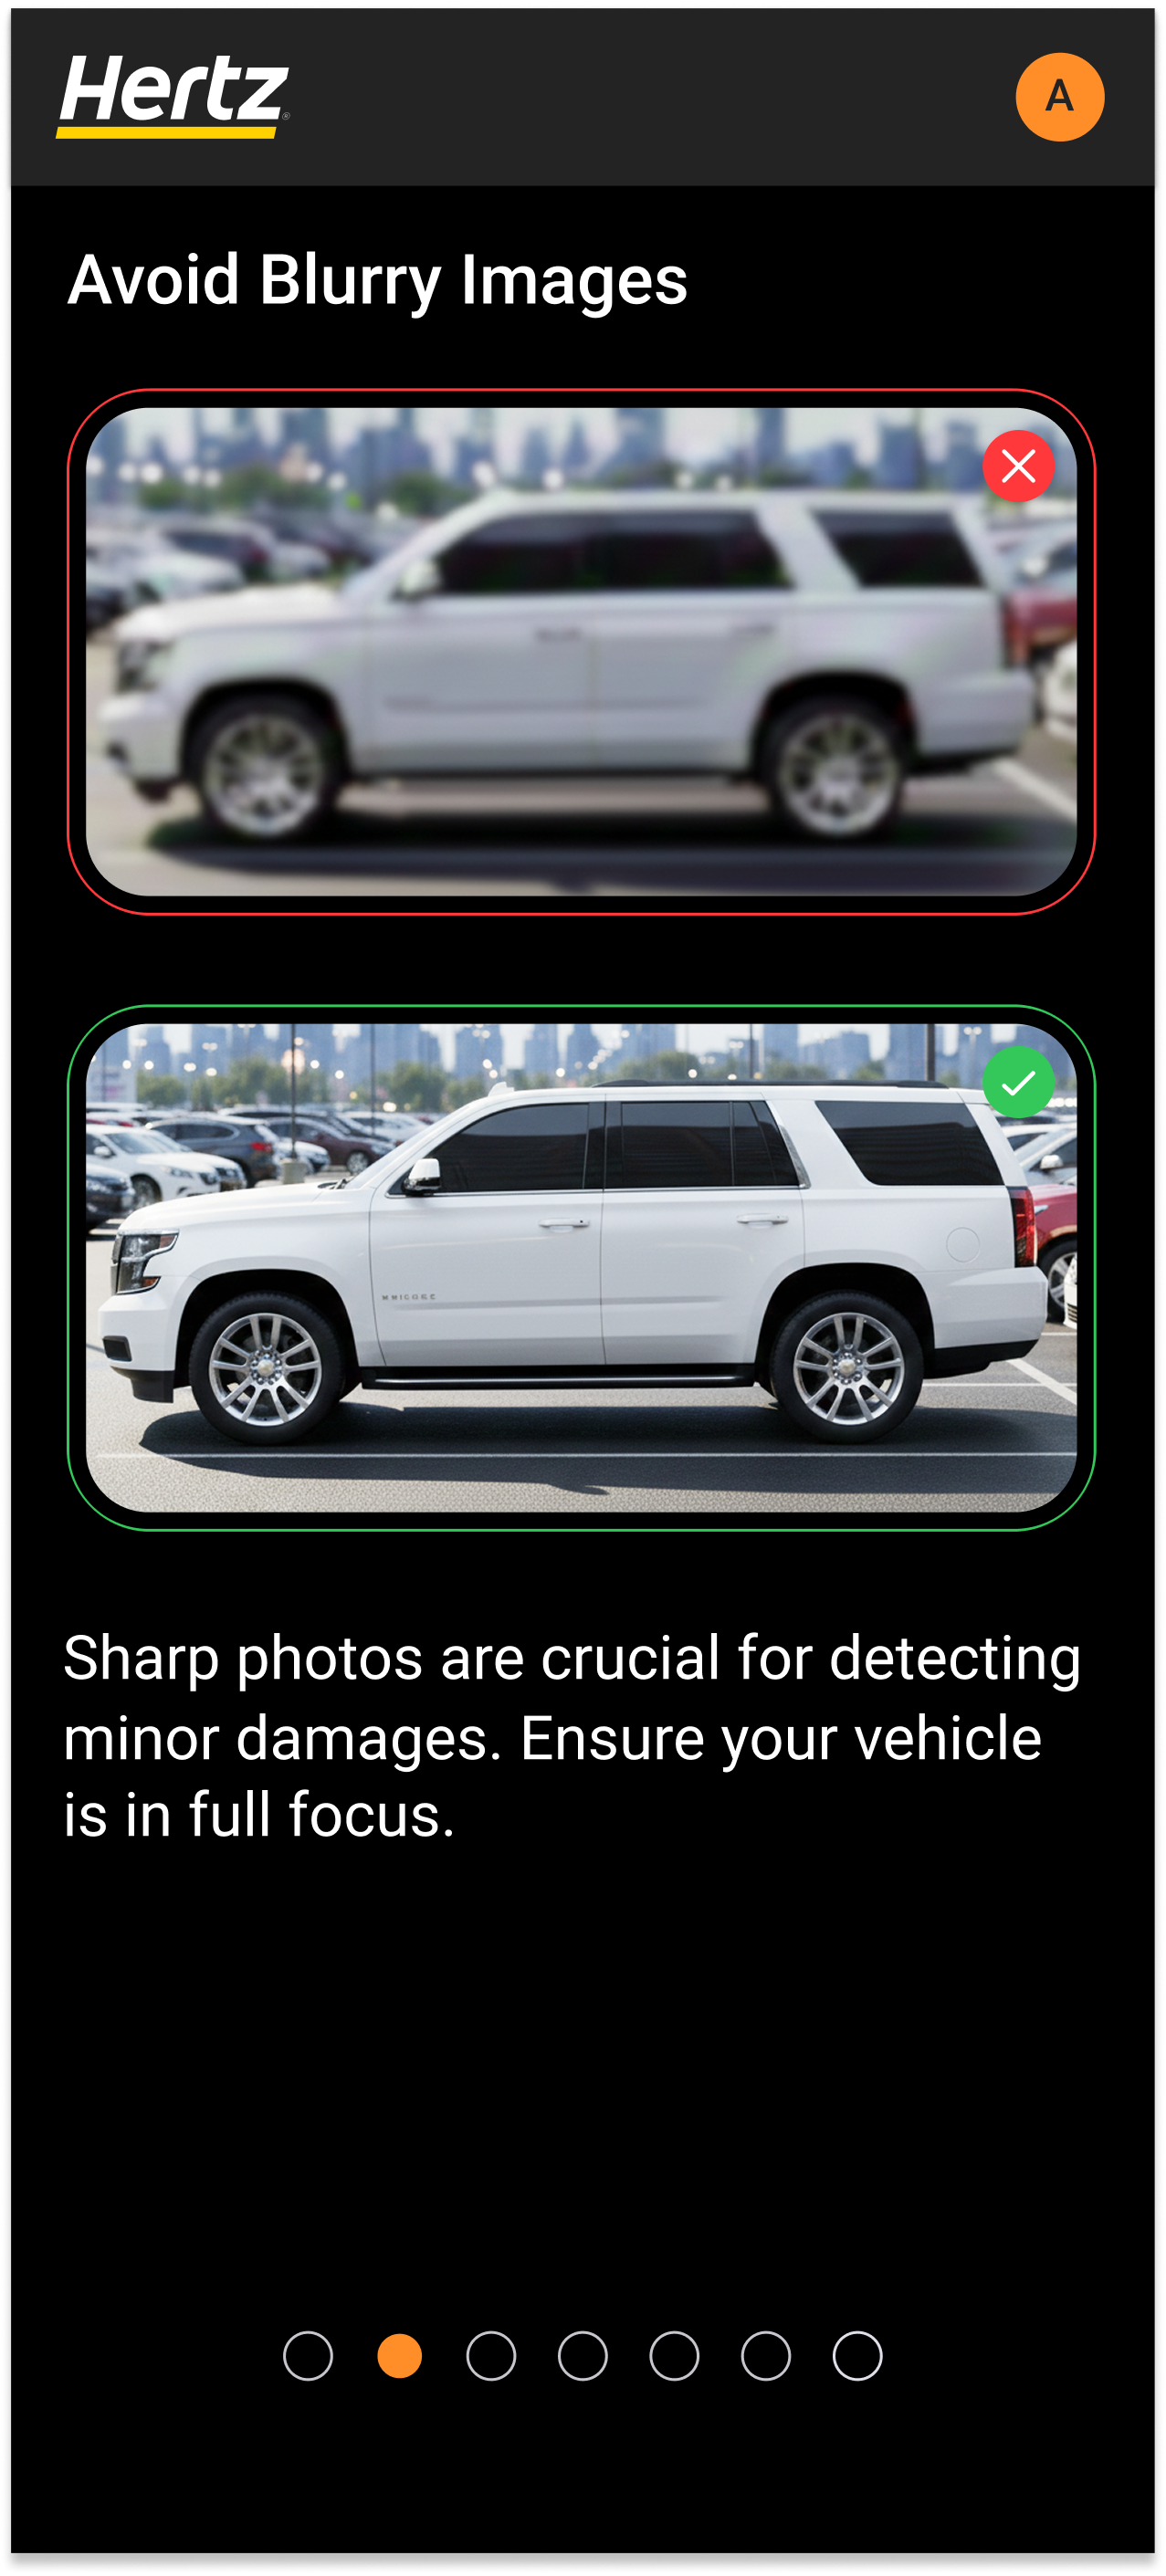
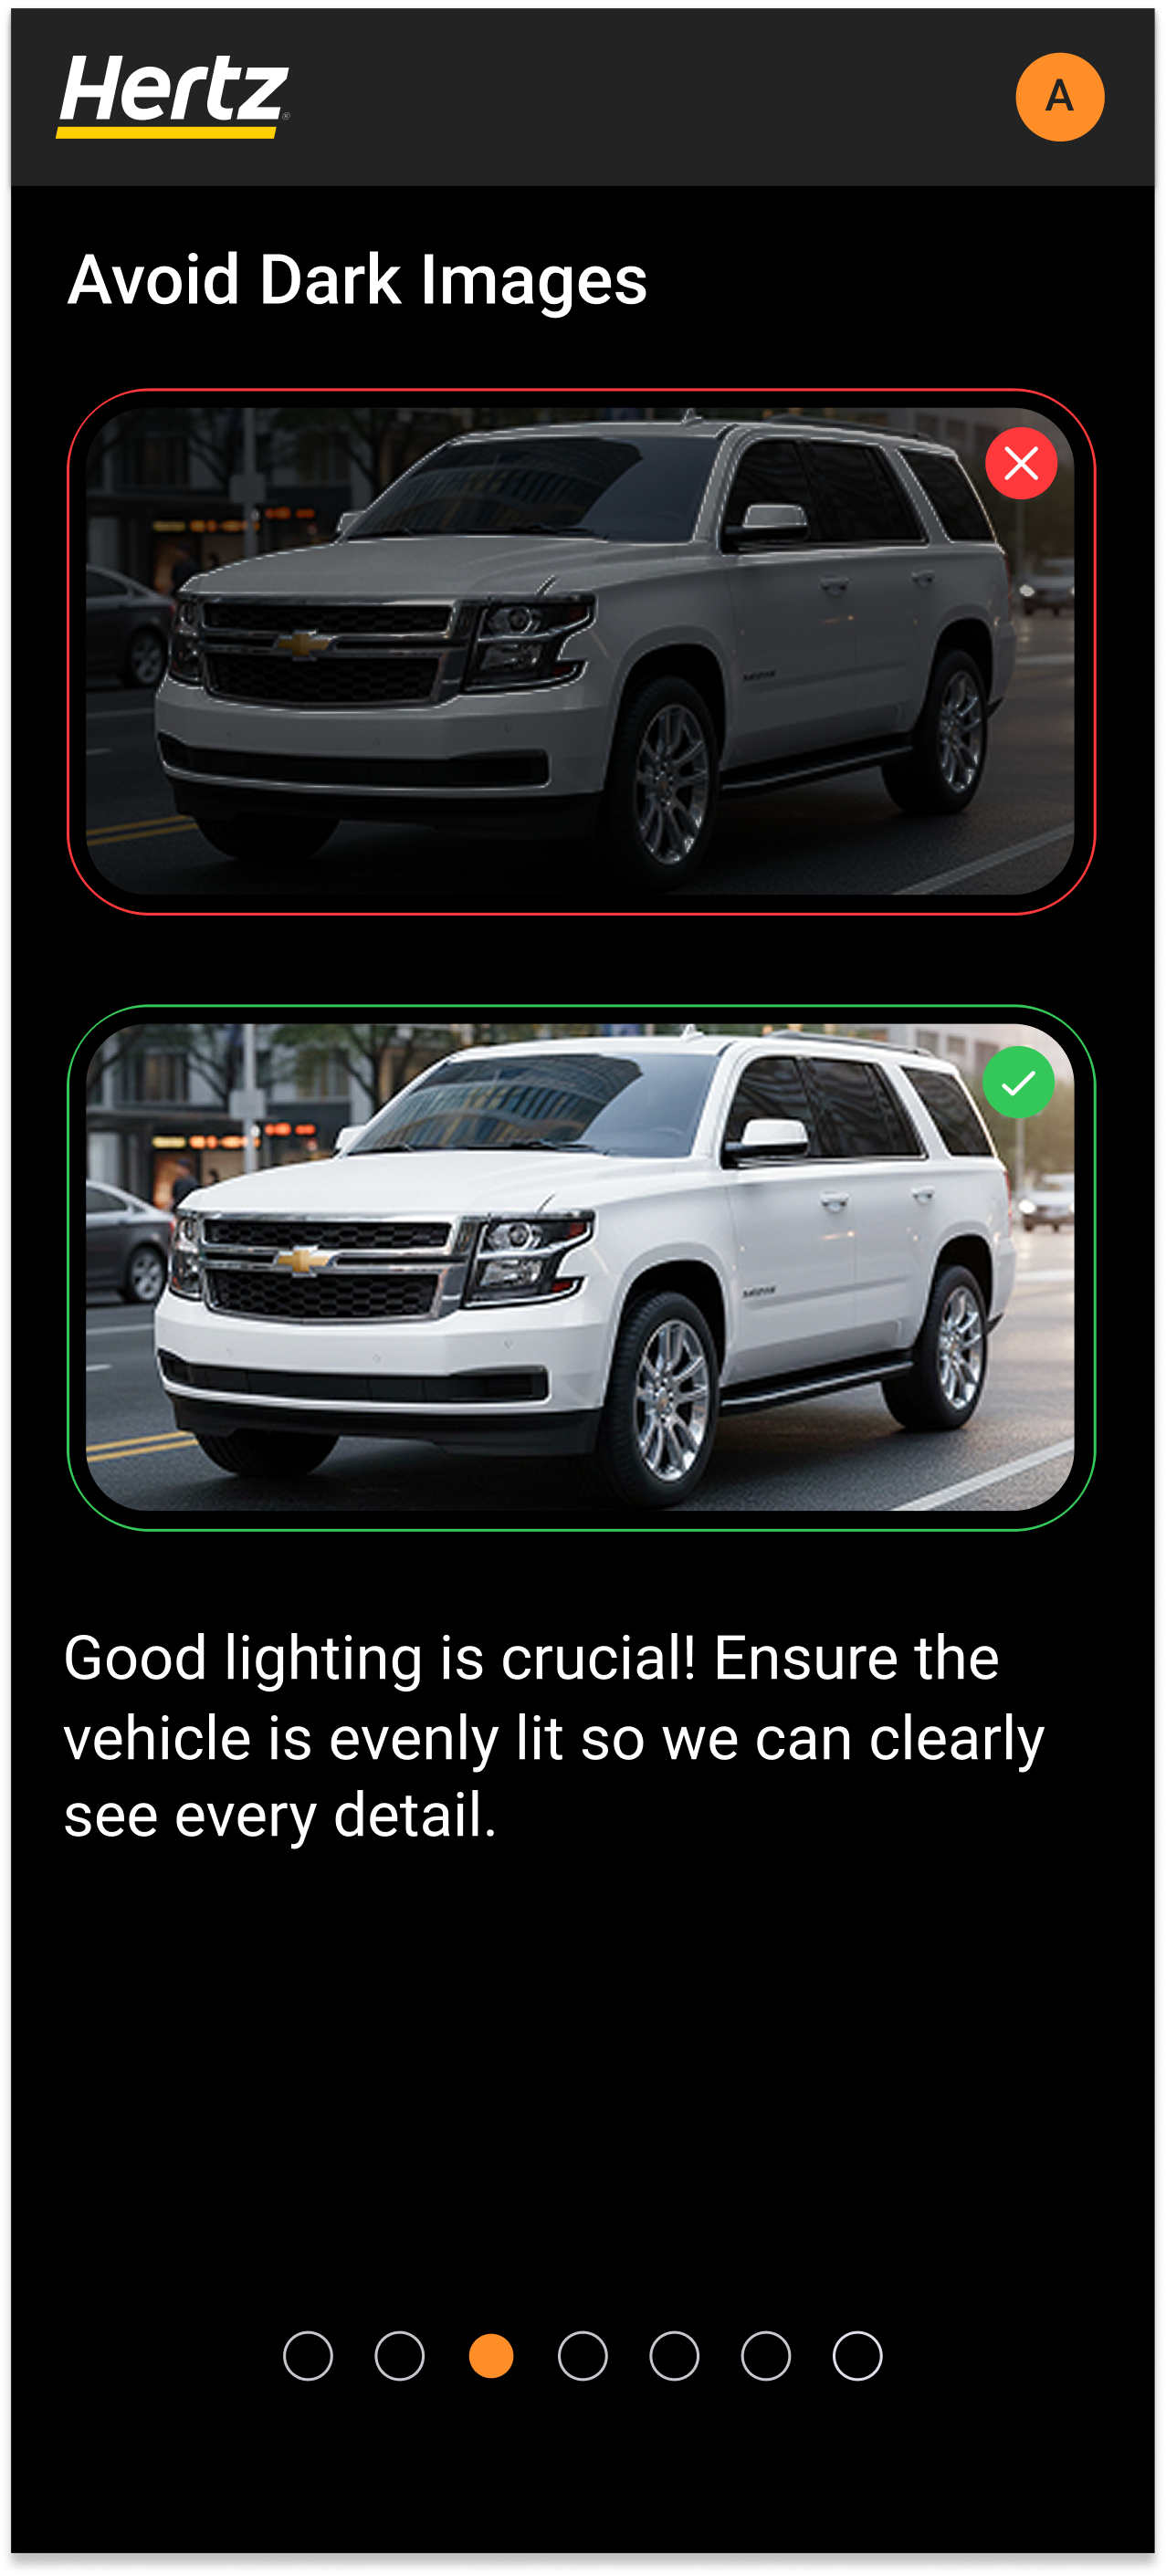
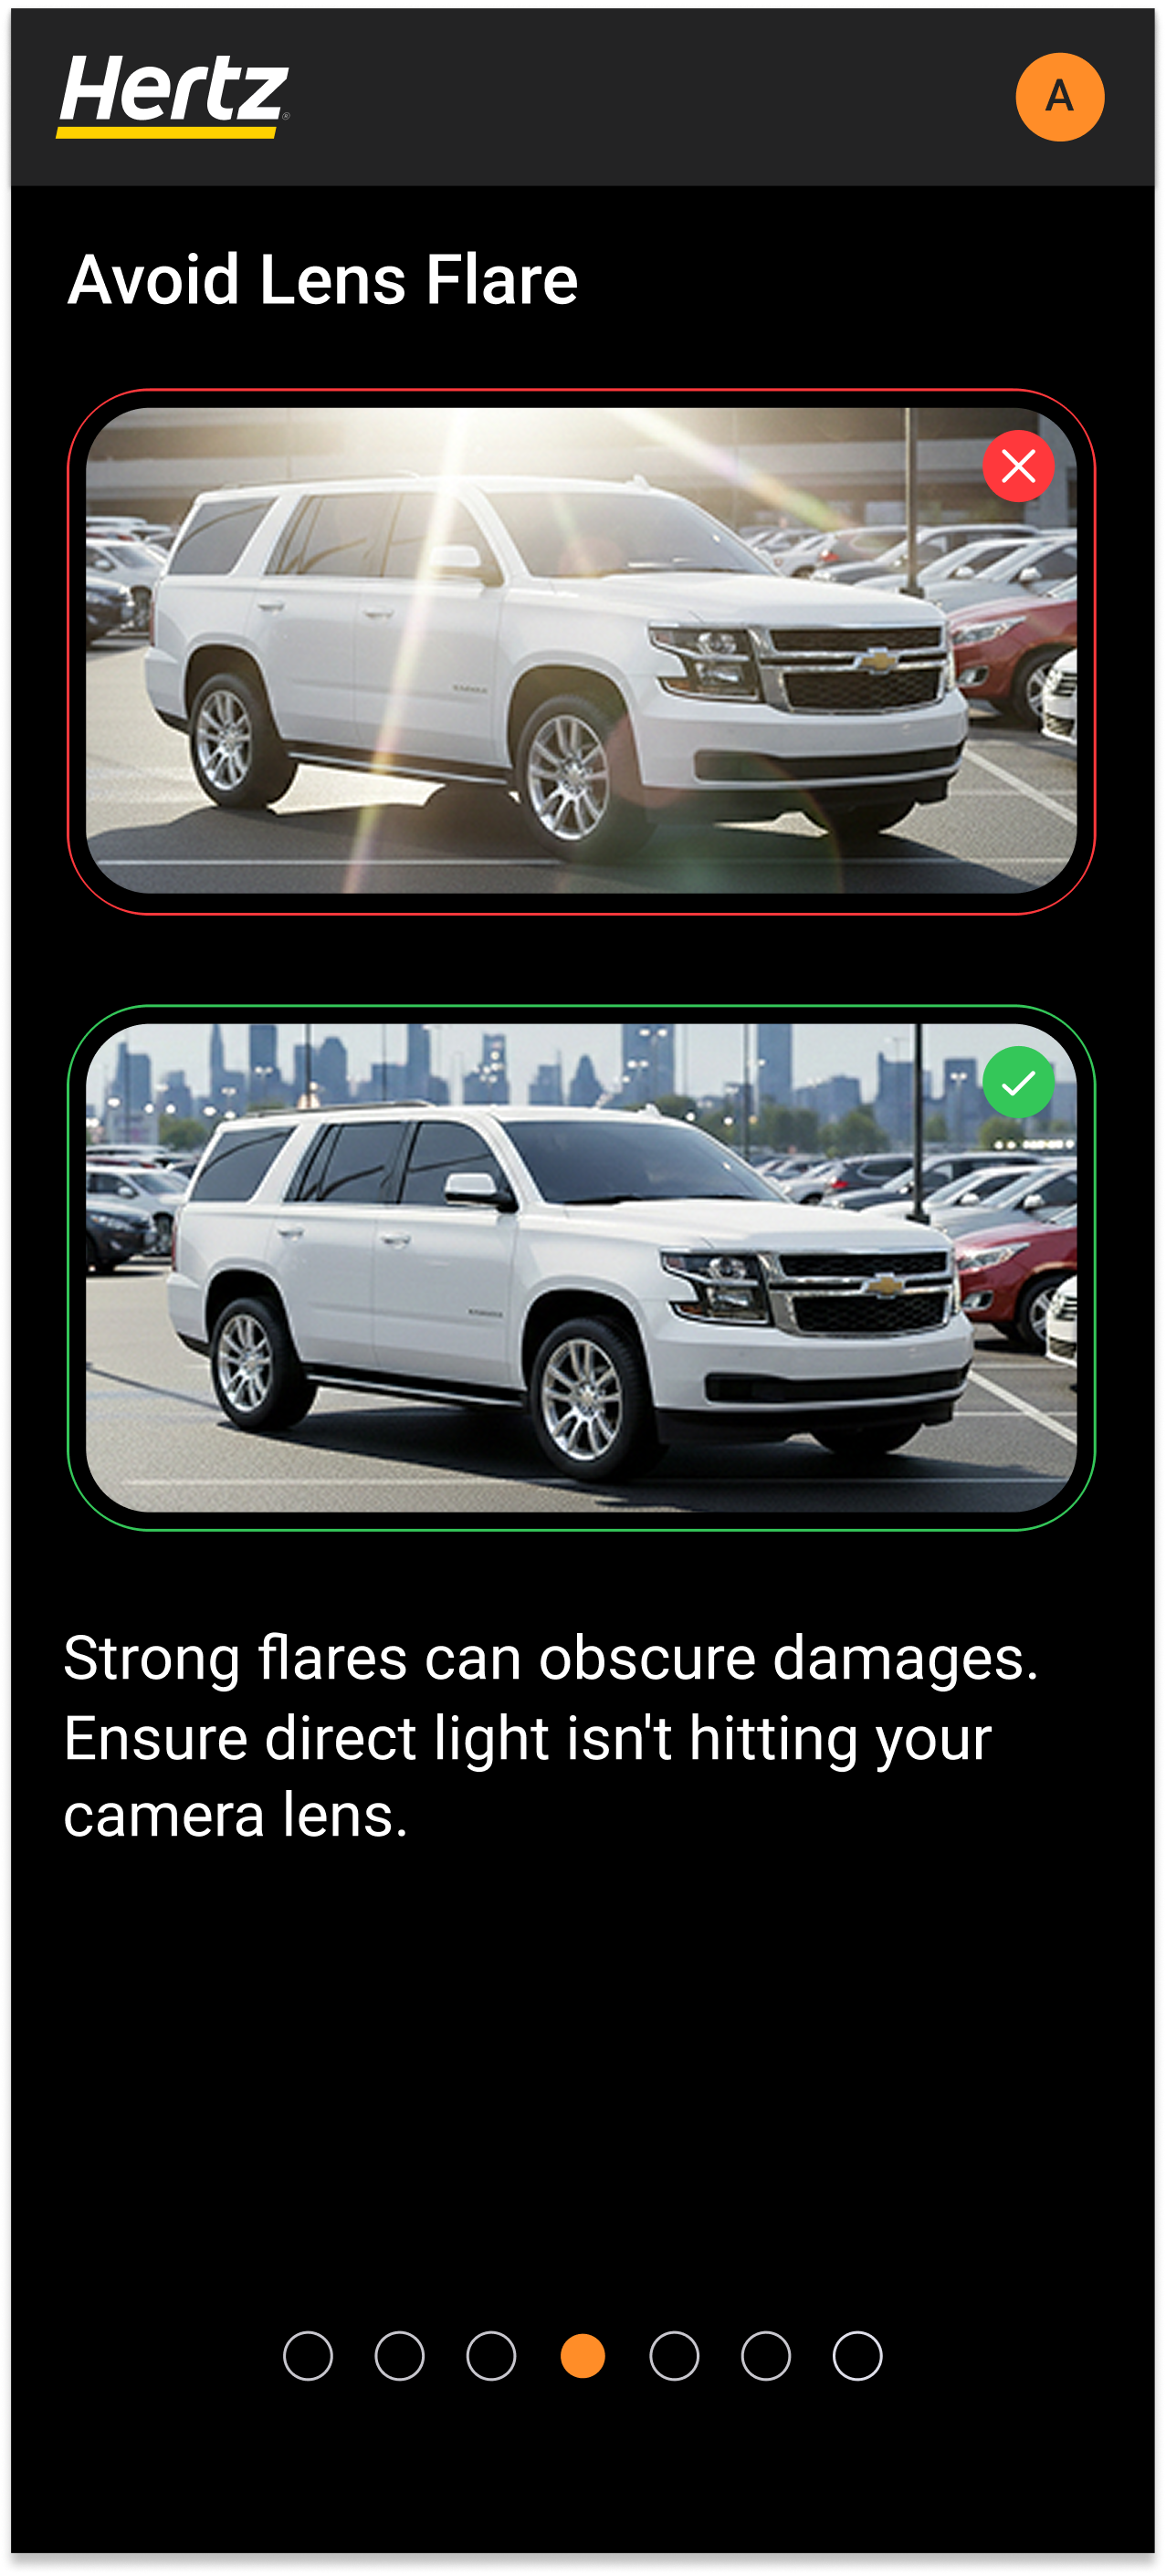
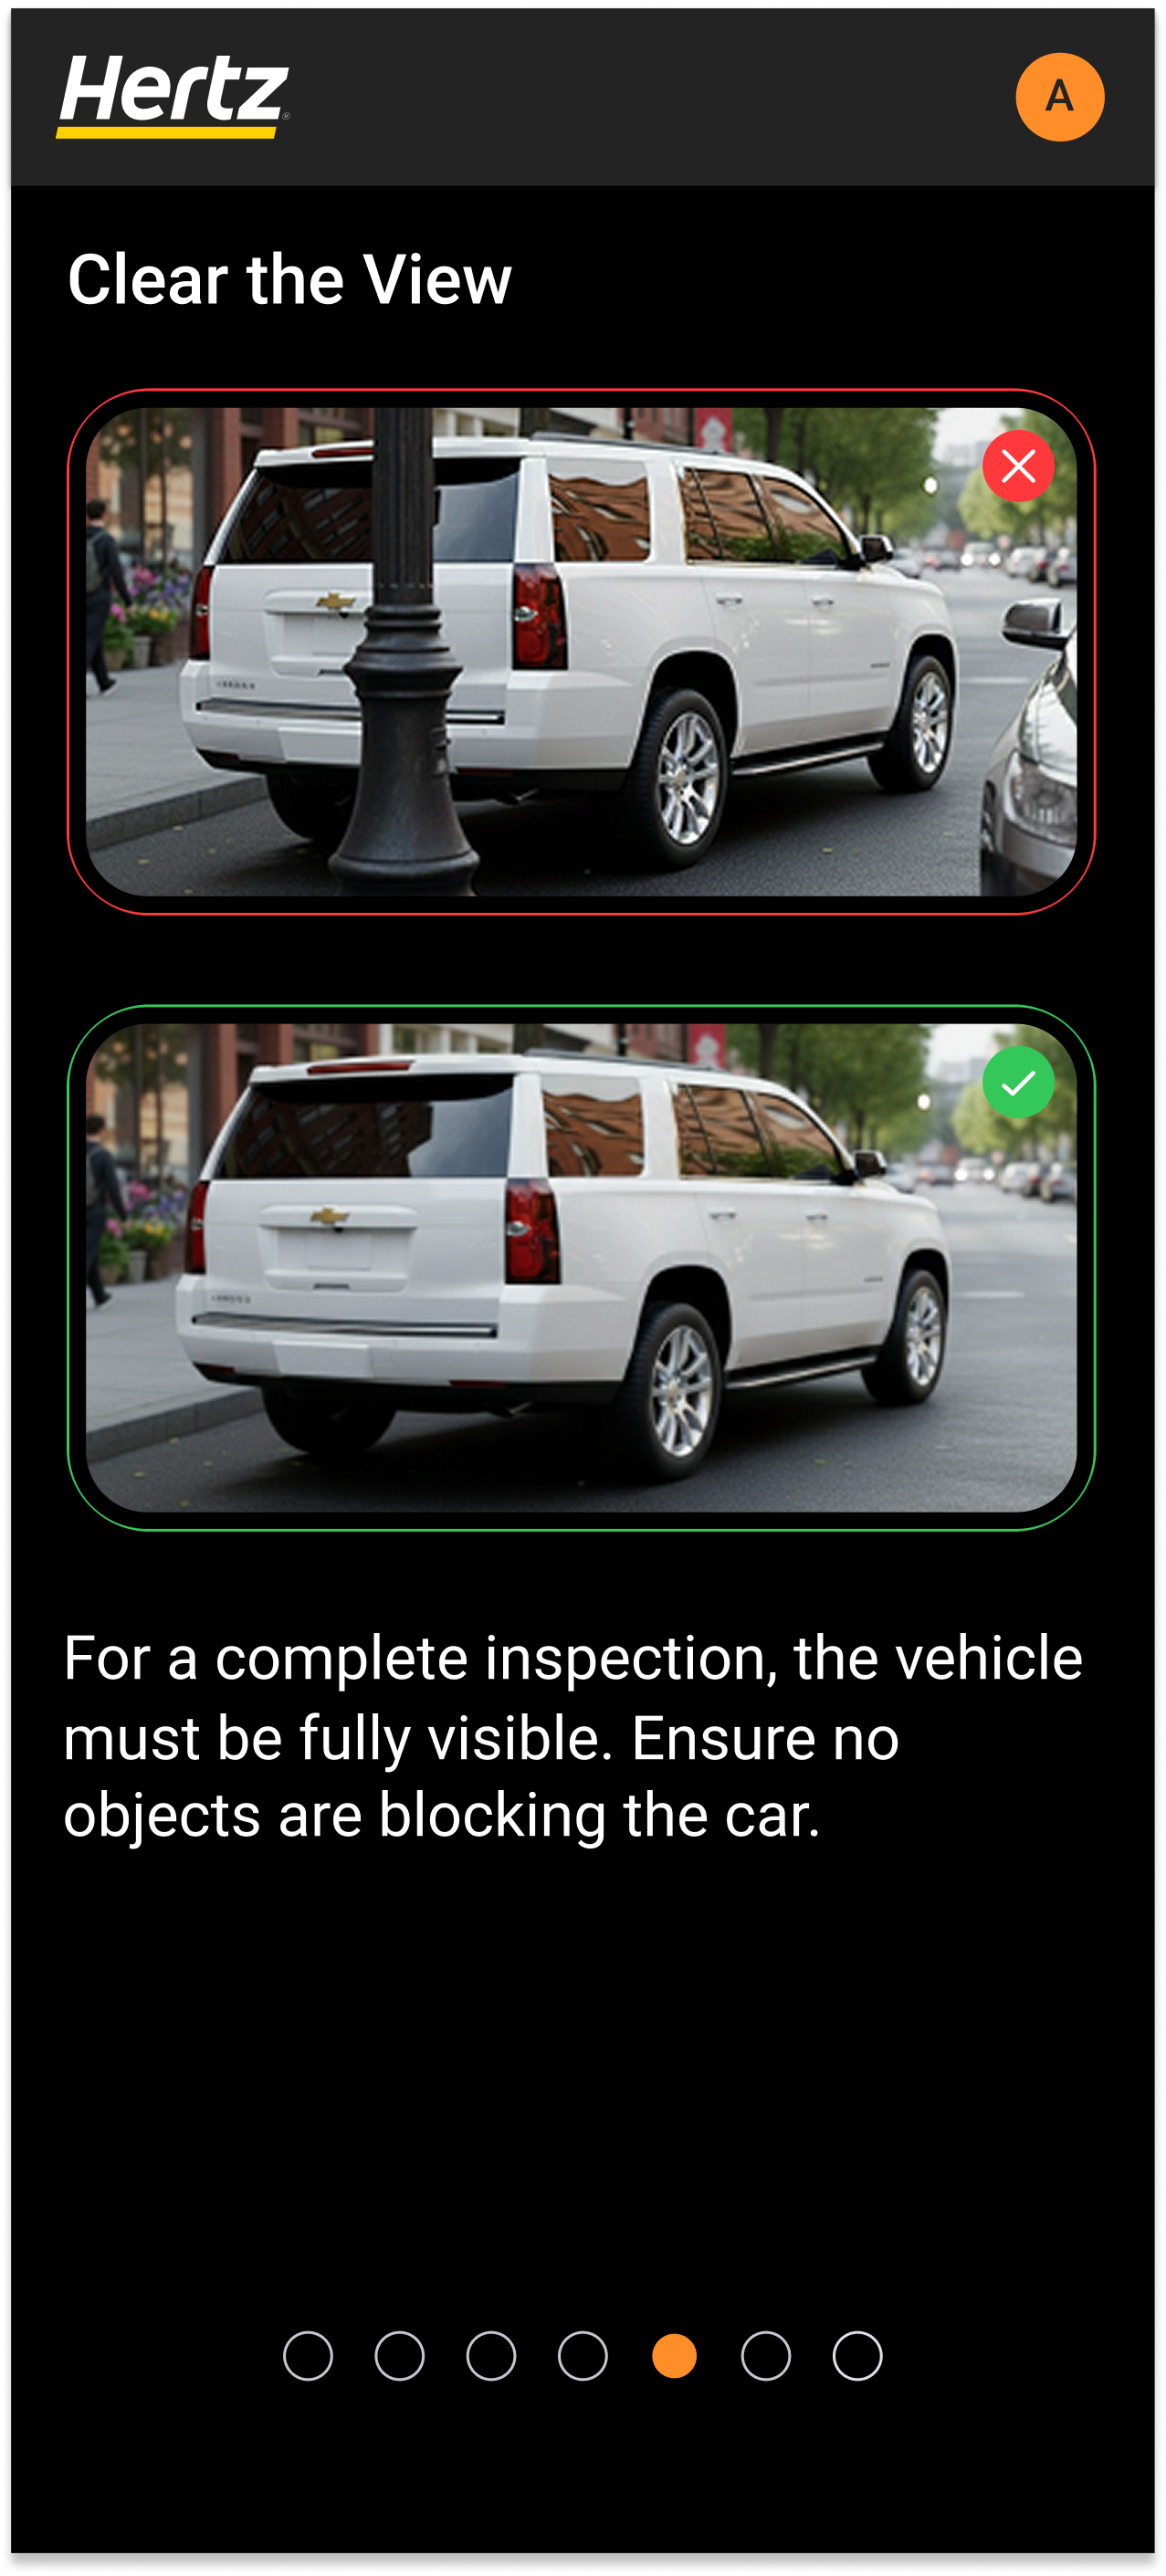
Before starting an inspection, agents complete a short visual tutorial that establishes the mental model for the entire capture process. It shows common failure conditions, including blurry or dark images, lens flare, and an obstructed view, then introduces the visual overlay and the framing expected during the live session.
By the time agents open the camera, they understand what a successful image looks like, how to position the vehicle in the frame, and what conditions to avoid.
Tutorial Overview
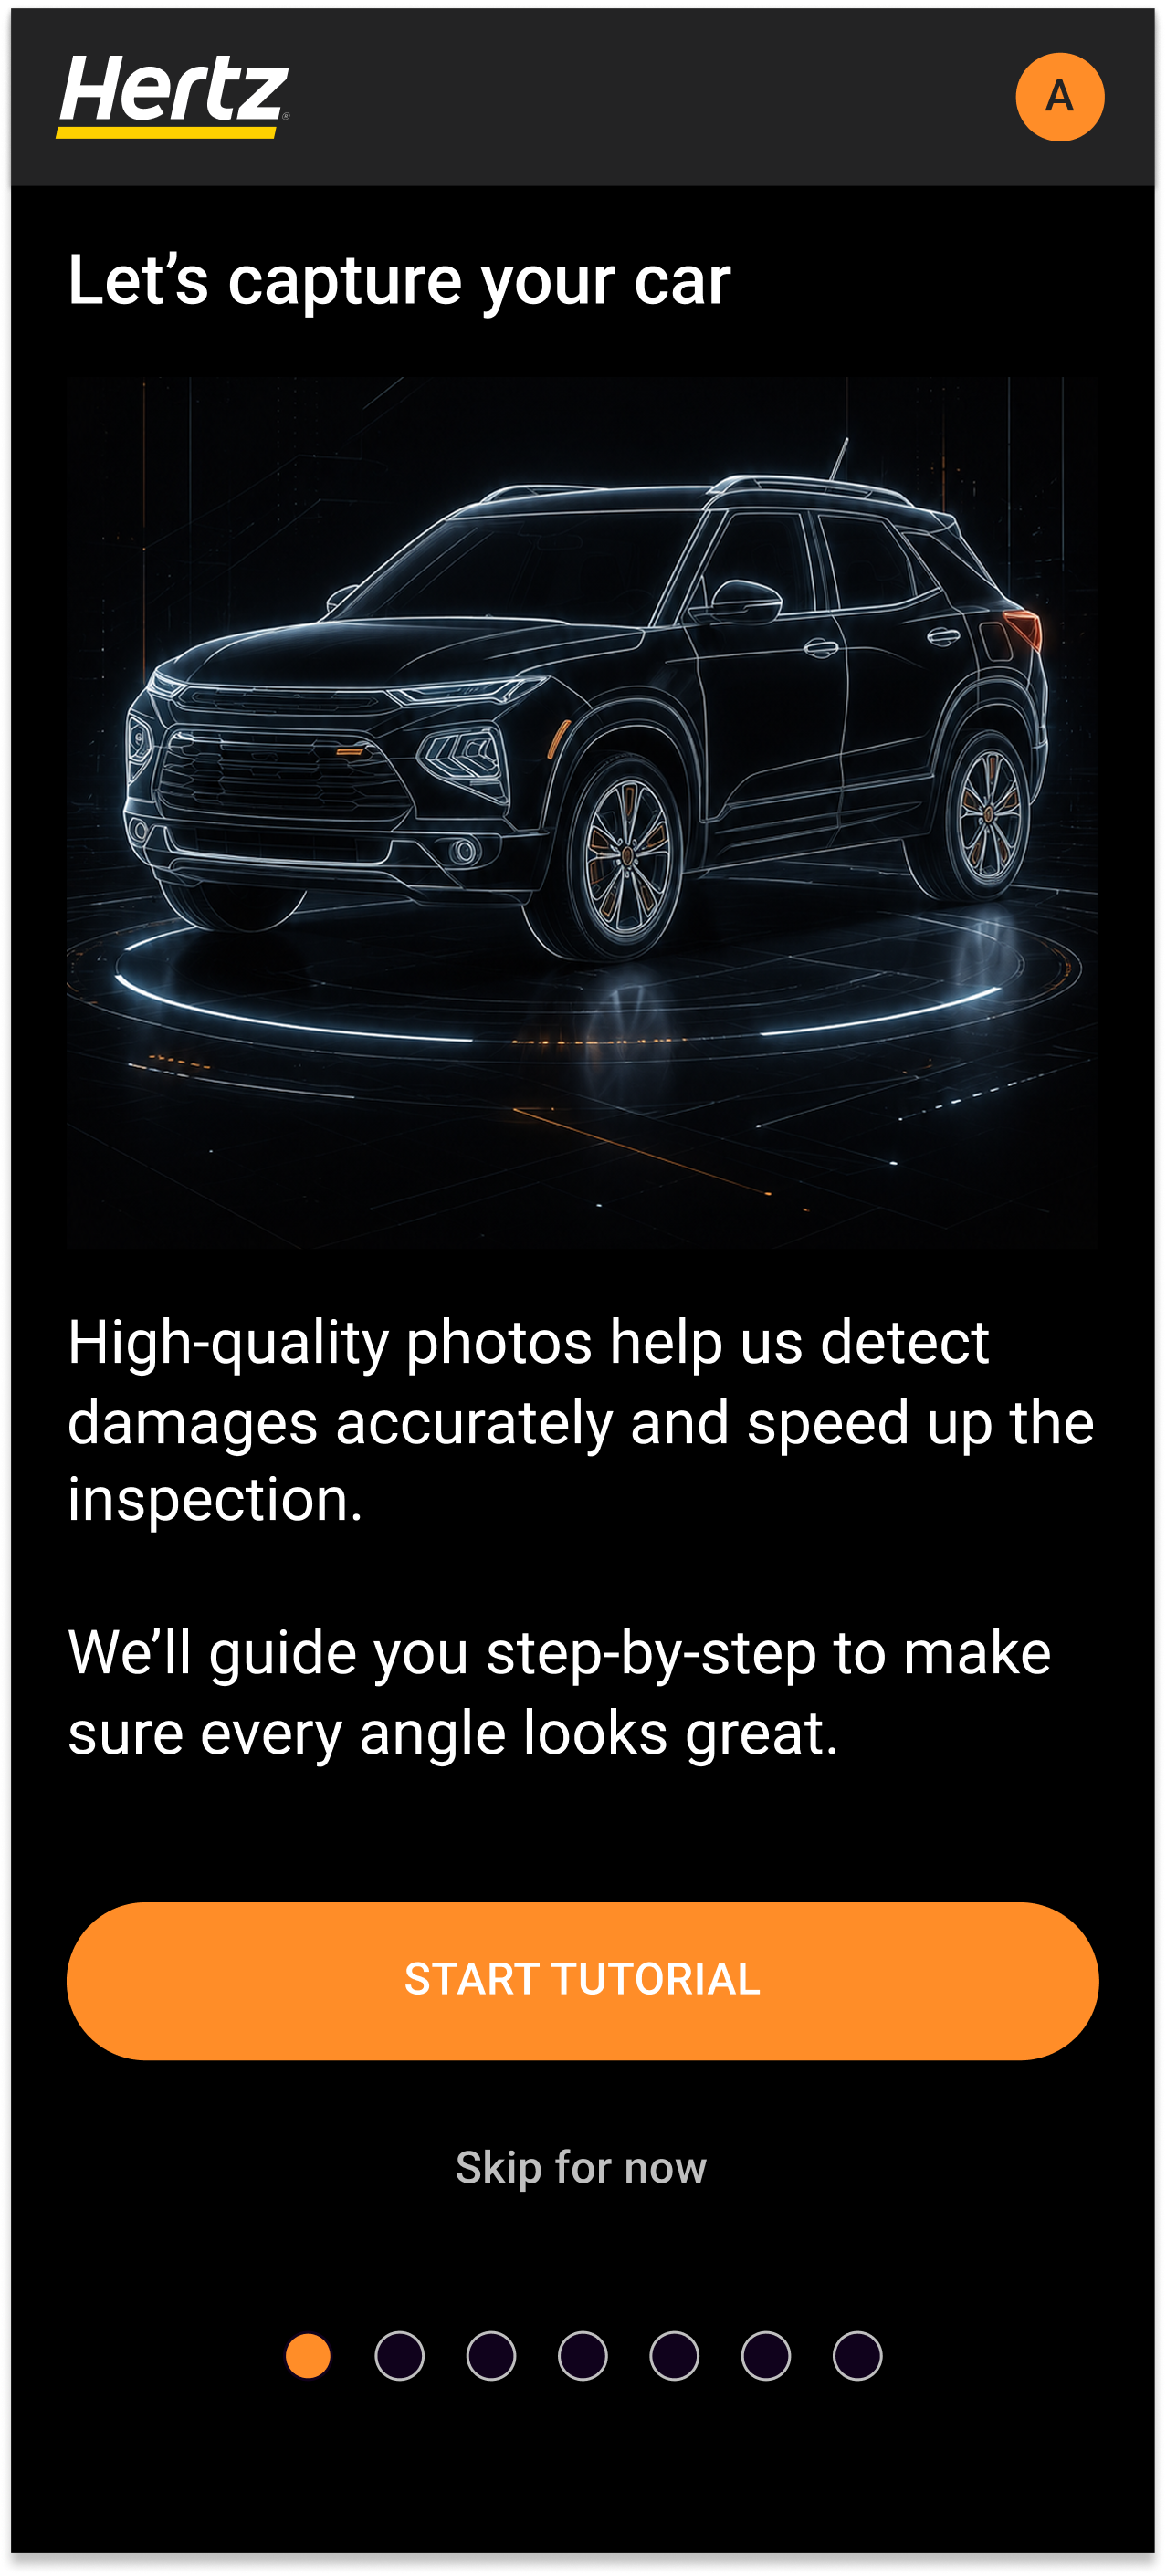
The visual walkthrough introduces the capture sequence, common image-quality problems, and the overlay agents will use during the live inspection.
Learn
Ready to Capture
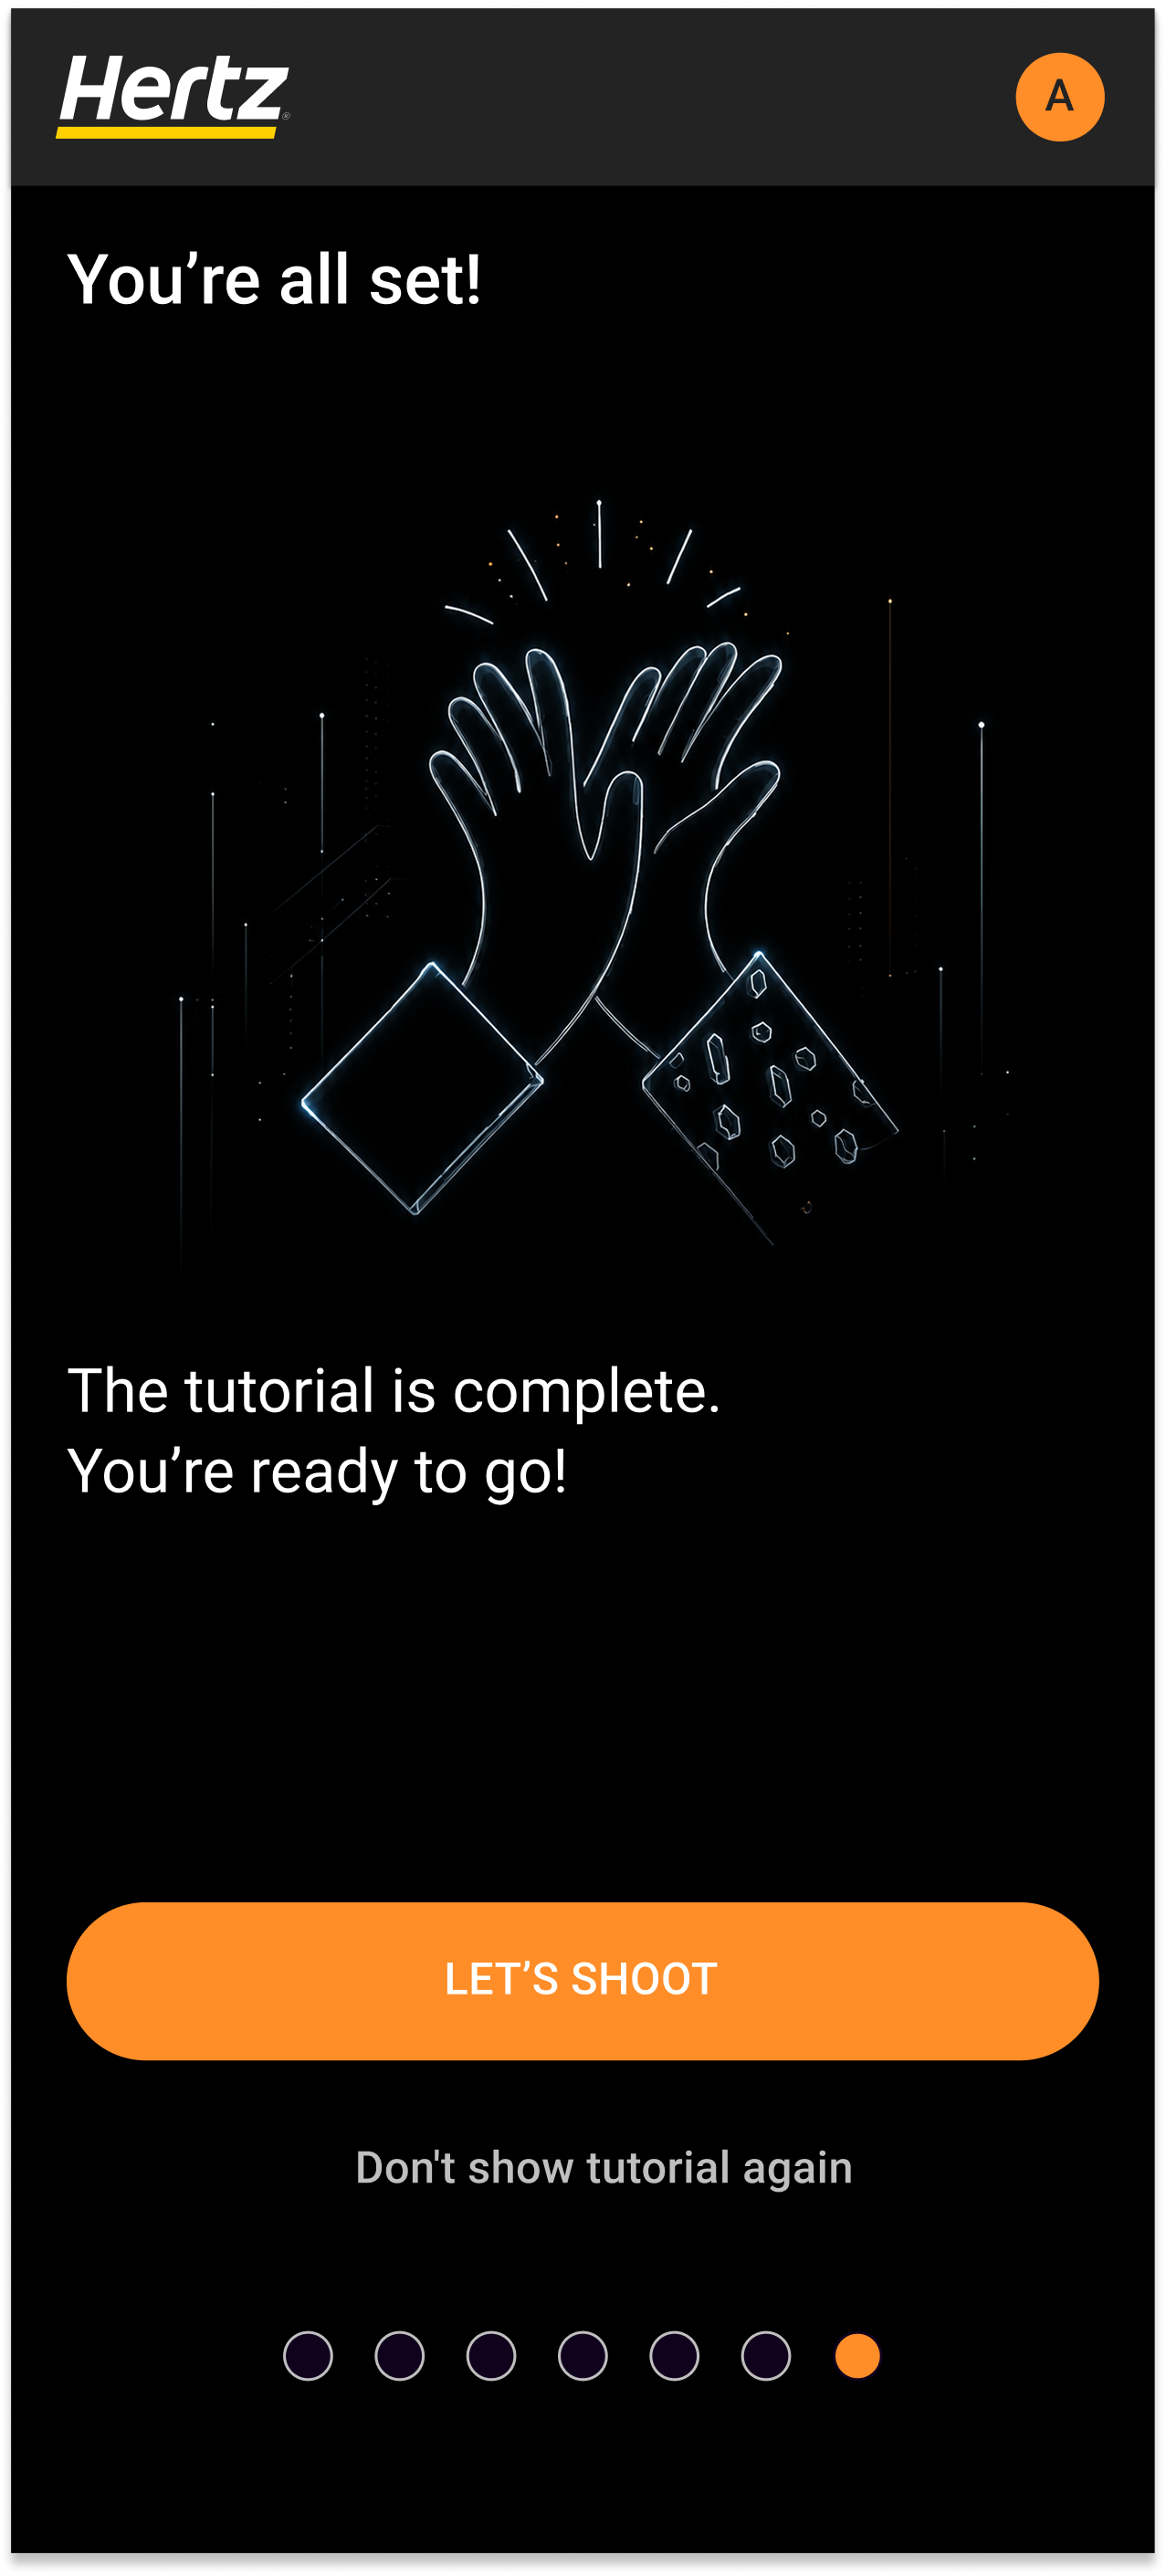
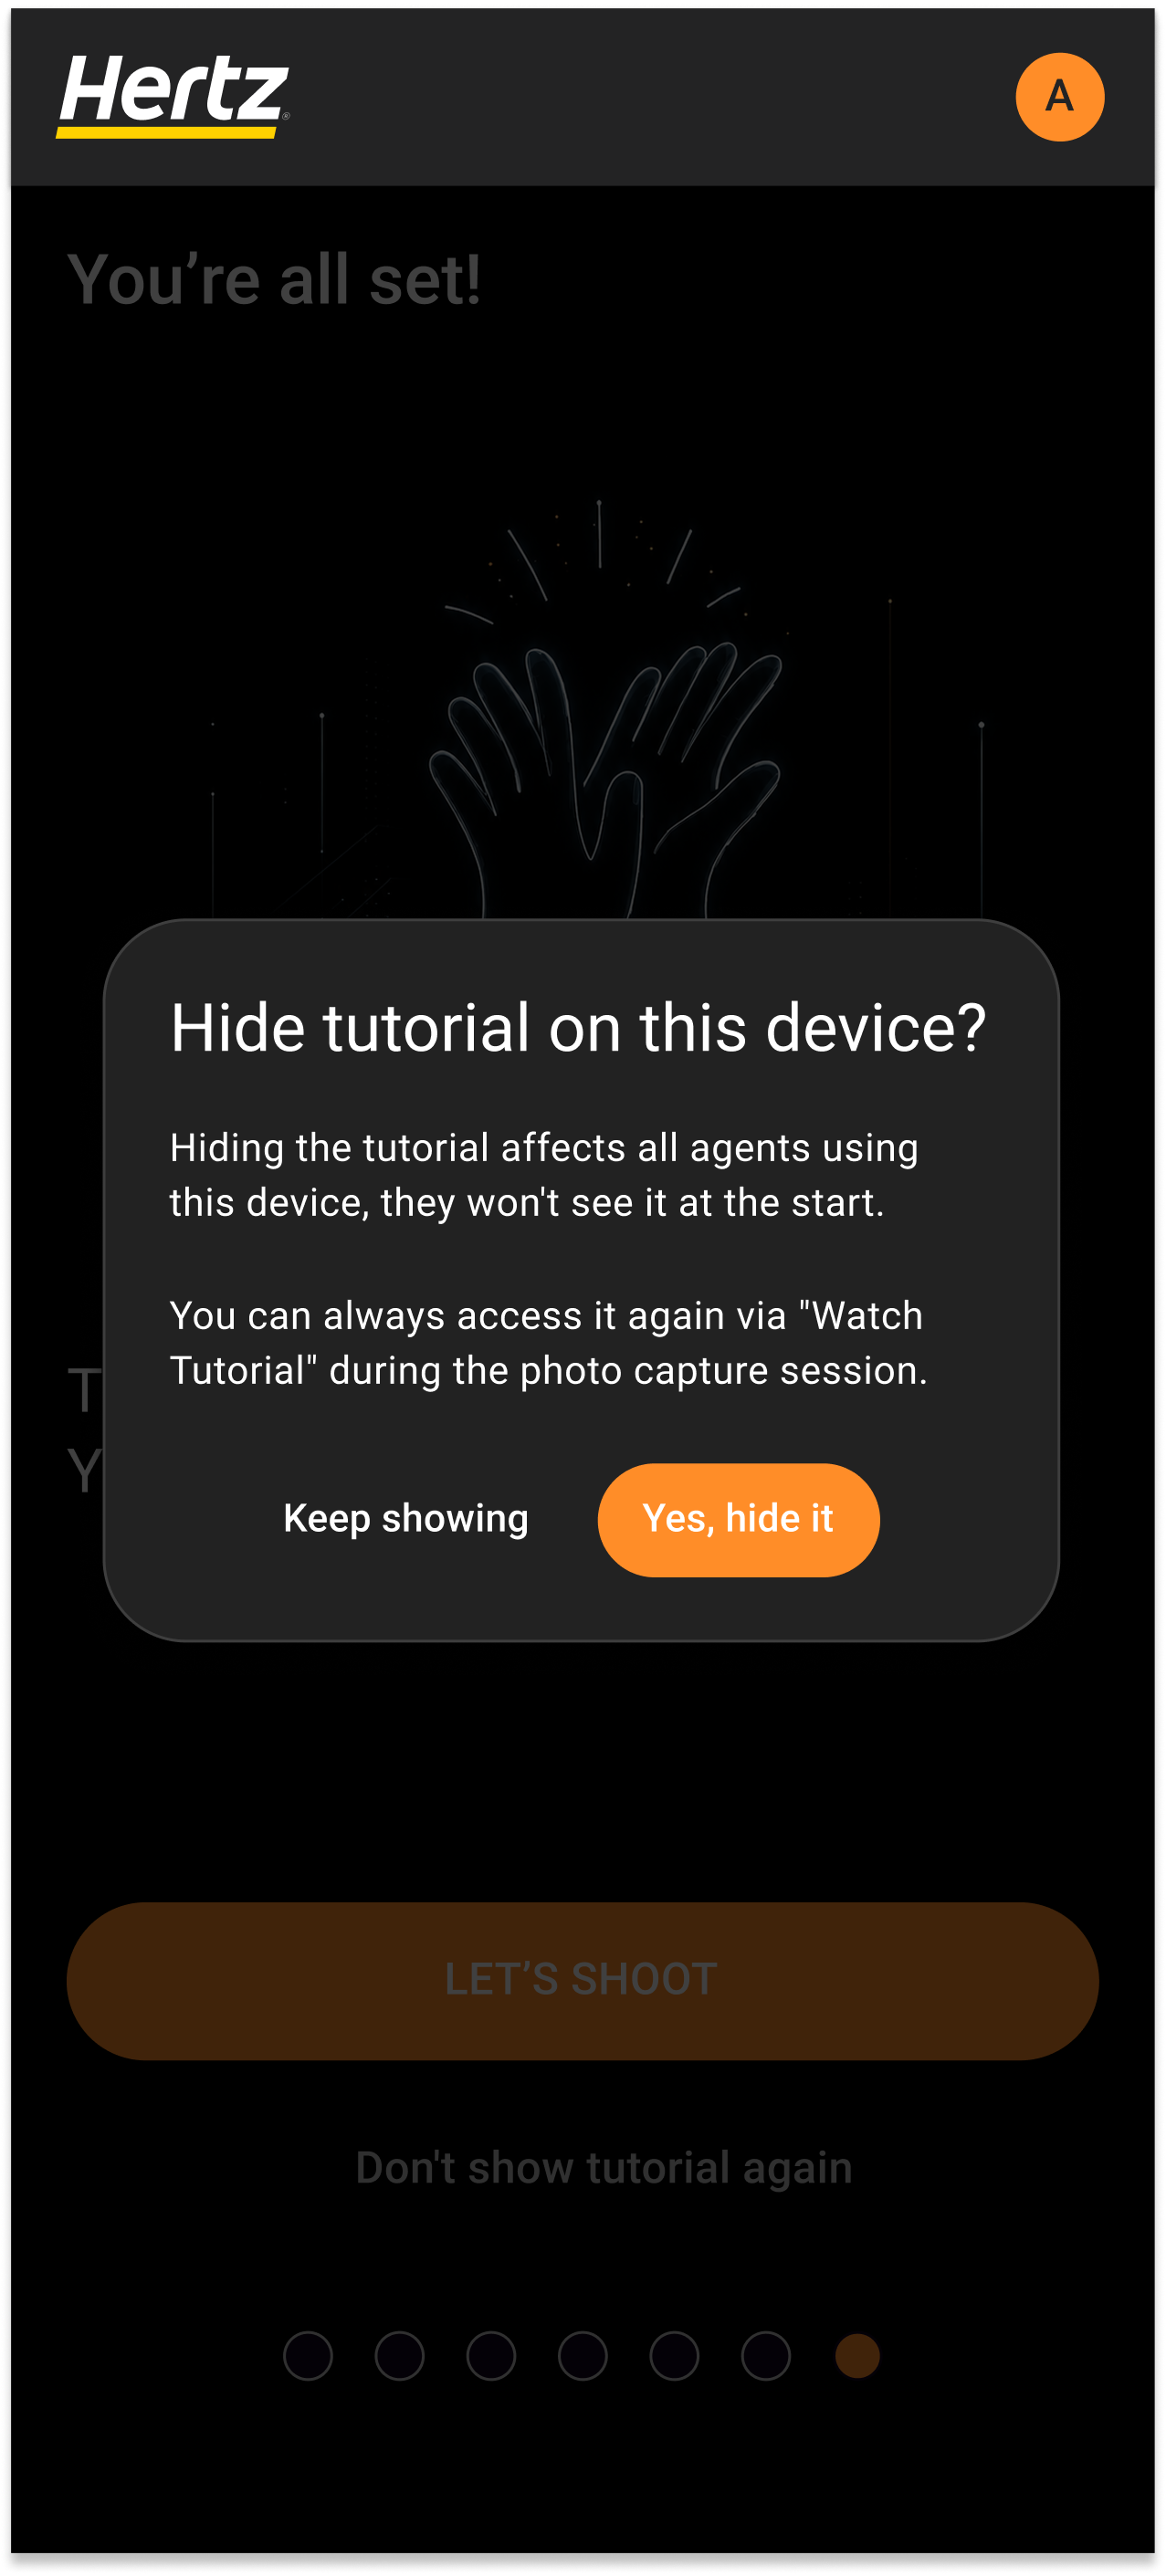
Rental locations often use shared devices across shifts, so tutorial visibility had to be managed at the device level rather than for each individual agent.
Hiding the tutorial requires an explicit confirmation explaining that the decision affects everyone using that device. Even after it is hidden, agents can reopen it at any time through the "Watch Tutorial" option during the inspection.
This allowed experienced agents to move faster without permanently removing support for new or less experienced staff.
At every capture step, the live camera displays a visual overlay showing agents where to stand, which area of the vehicle to capture, and how to frame it. A vehicle outline, highlighted capture area, angle reference, and progress indicator work together to guide the shot before the shutter is pressed.
To bridge the gap between the tutorial and the live camera, a short transition animation shows how the reference vehicle becomes the on-screen overlay. This helps agents apply what they have learned at the exact moment they begin capturing.
The agent's task becomes alignment, not interpretation.
A key design decision was to use category-based overlays rather than attempt to recognize every specific vehicle model. Exact model recognition would add significant technical complexity and could leave gaps when the system encountered unfamiliar vehicles.
Instead, I worked with eight vehicle categories: SUV, Sedan, Minivan, Pickup Crew, Passenger Van, four-door Hatchback, two-door Hatchback, and Sports. The overlay did not need to reproduce every vehicle perfectly. It needed to make the required position and framing immediately clear.
This approach created a scalable guidance system that could support a broad range of vehicles without depending on exact make-and-model recognition.
Because no single guidance mechanism could prevent every error, I designed five complementary layers that support agents at different moments in the inspection.
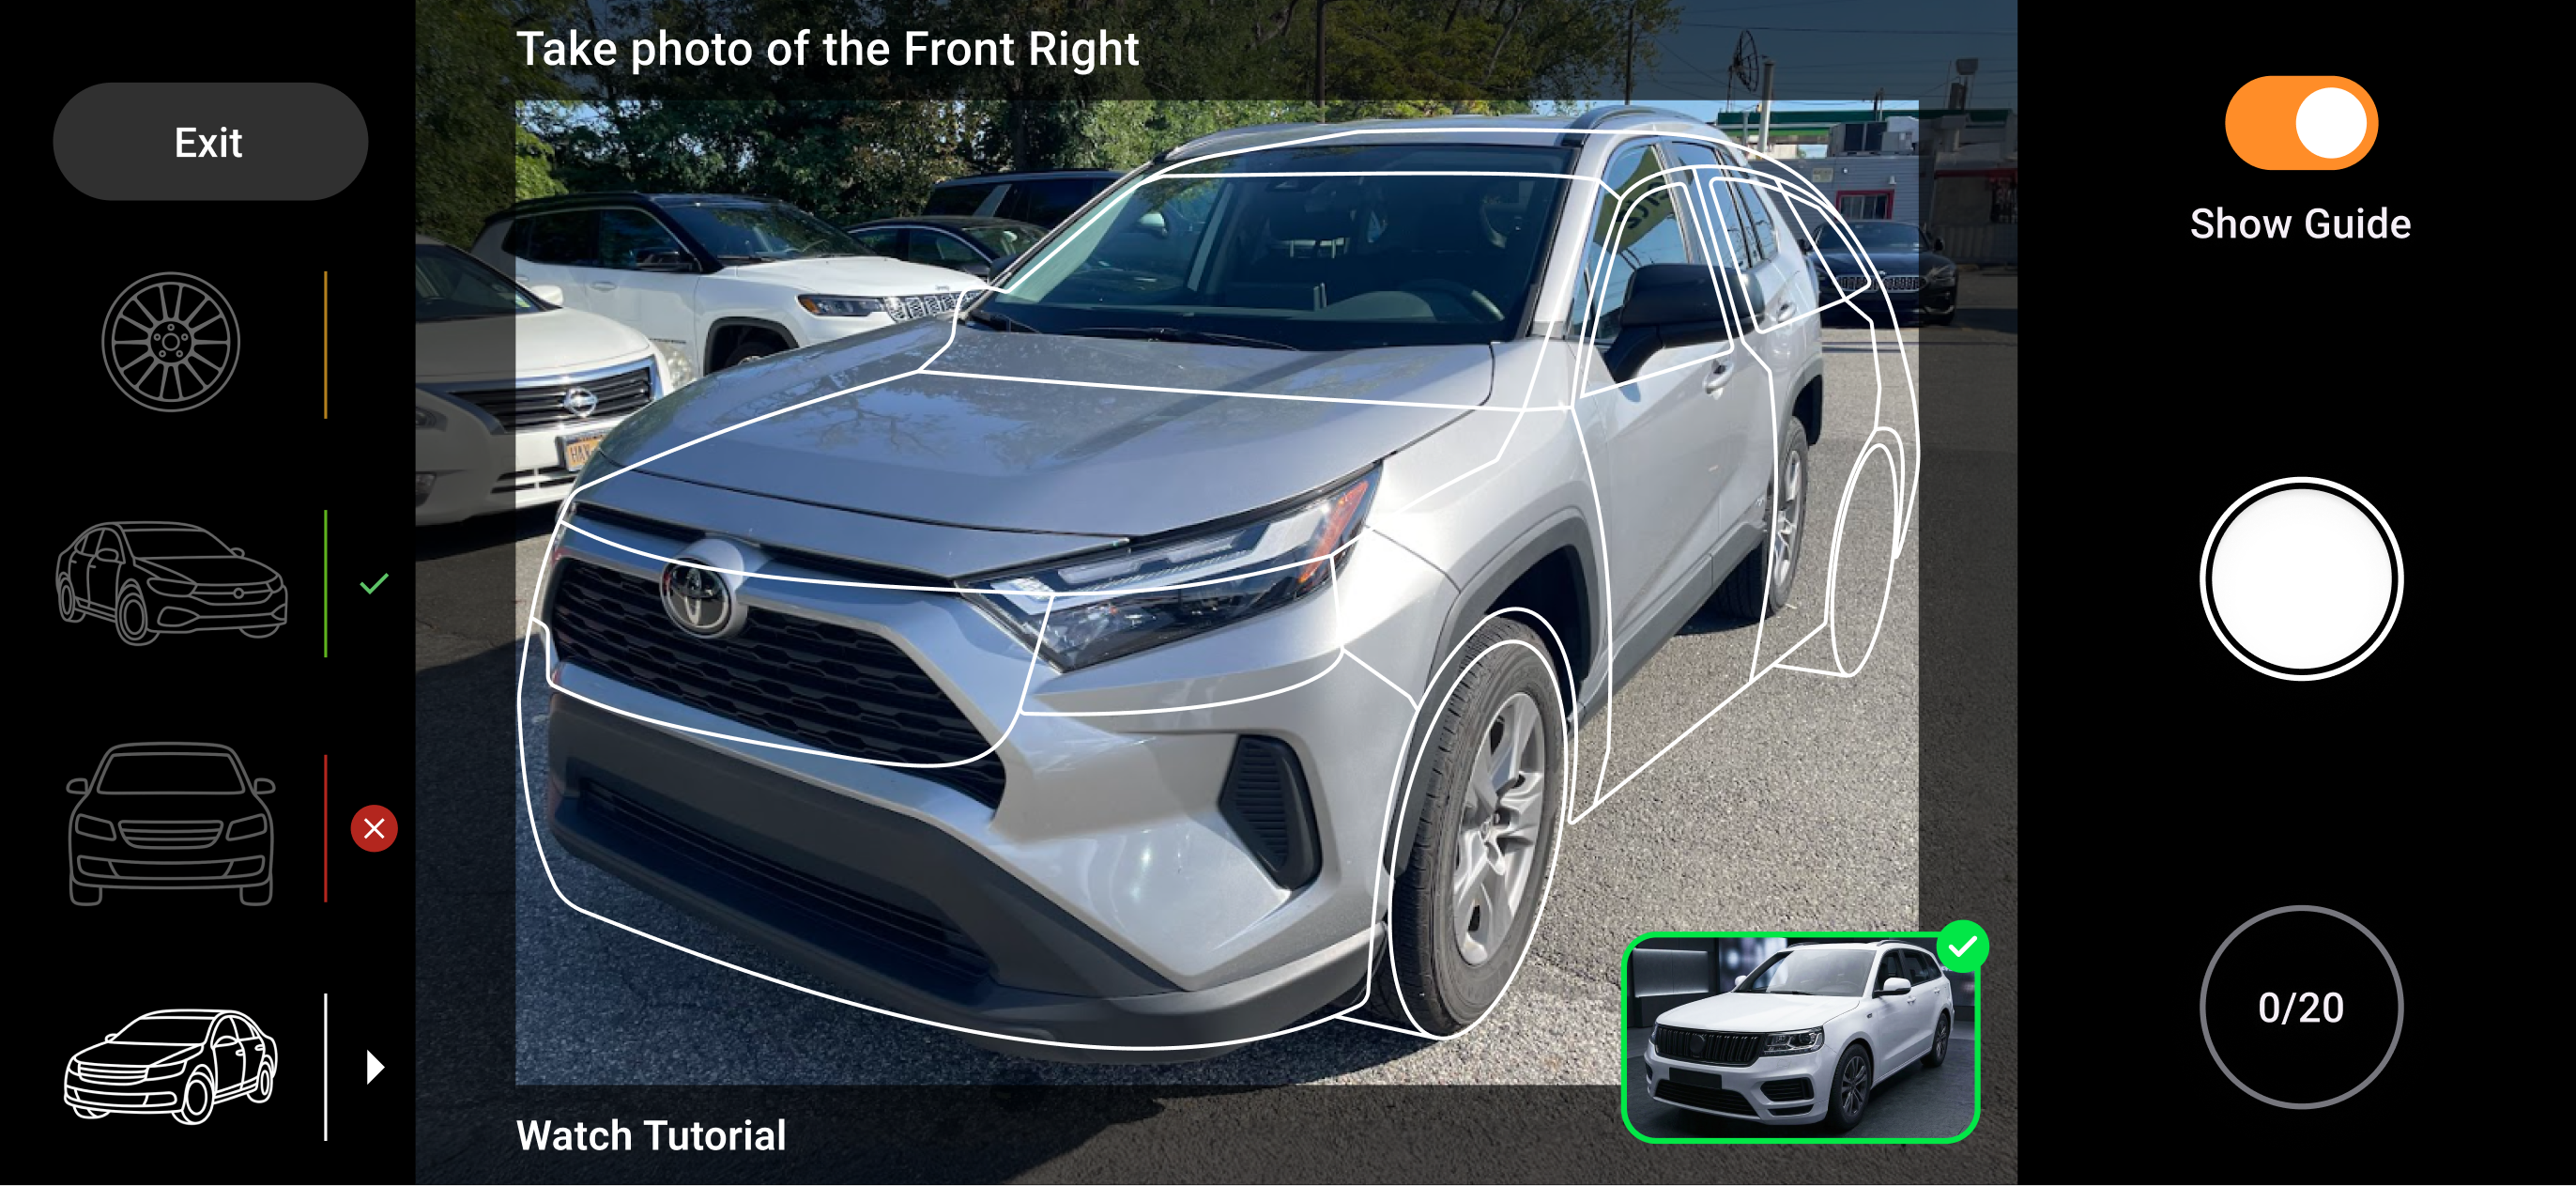
Guides the agent toward the correct position and framing.
Shows the required angle and vehicle area for each shot.
Makes completed and remaining inspection steps visible.
Provides contextual support when a new or difficult action begins.
Allows experienced agents to reduce visual guidance when they no longer need it.
Together, these layers turn a complex inspection into a clear step-by-step process without depending on any single component to be perfect.
The tutorial established the basic capture principles, but agents could not be expected to remember every instruction throughout a 20-photo inspection, especially while working under time pressure. The product therefore needed to reinforce the right guidance at the moment it became relevant.
I designed contextual support around three moments in the inspection where uncertainty was most likely to affect image quality.
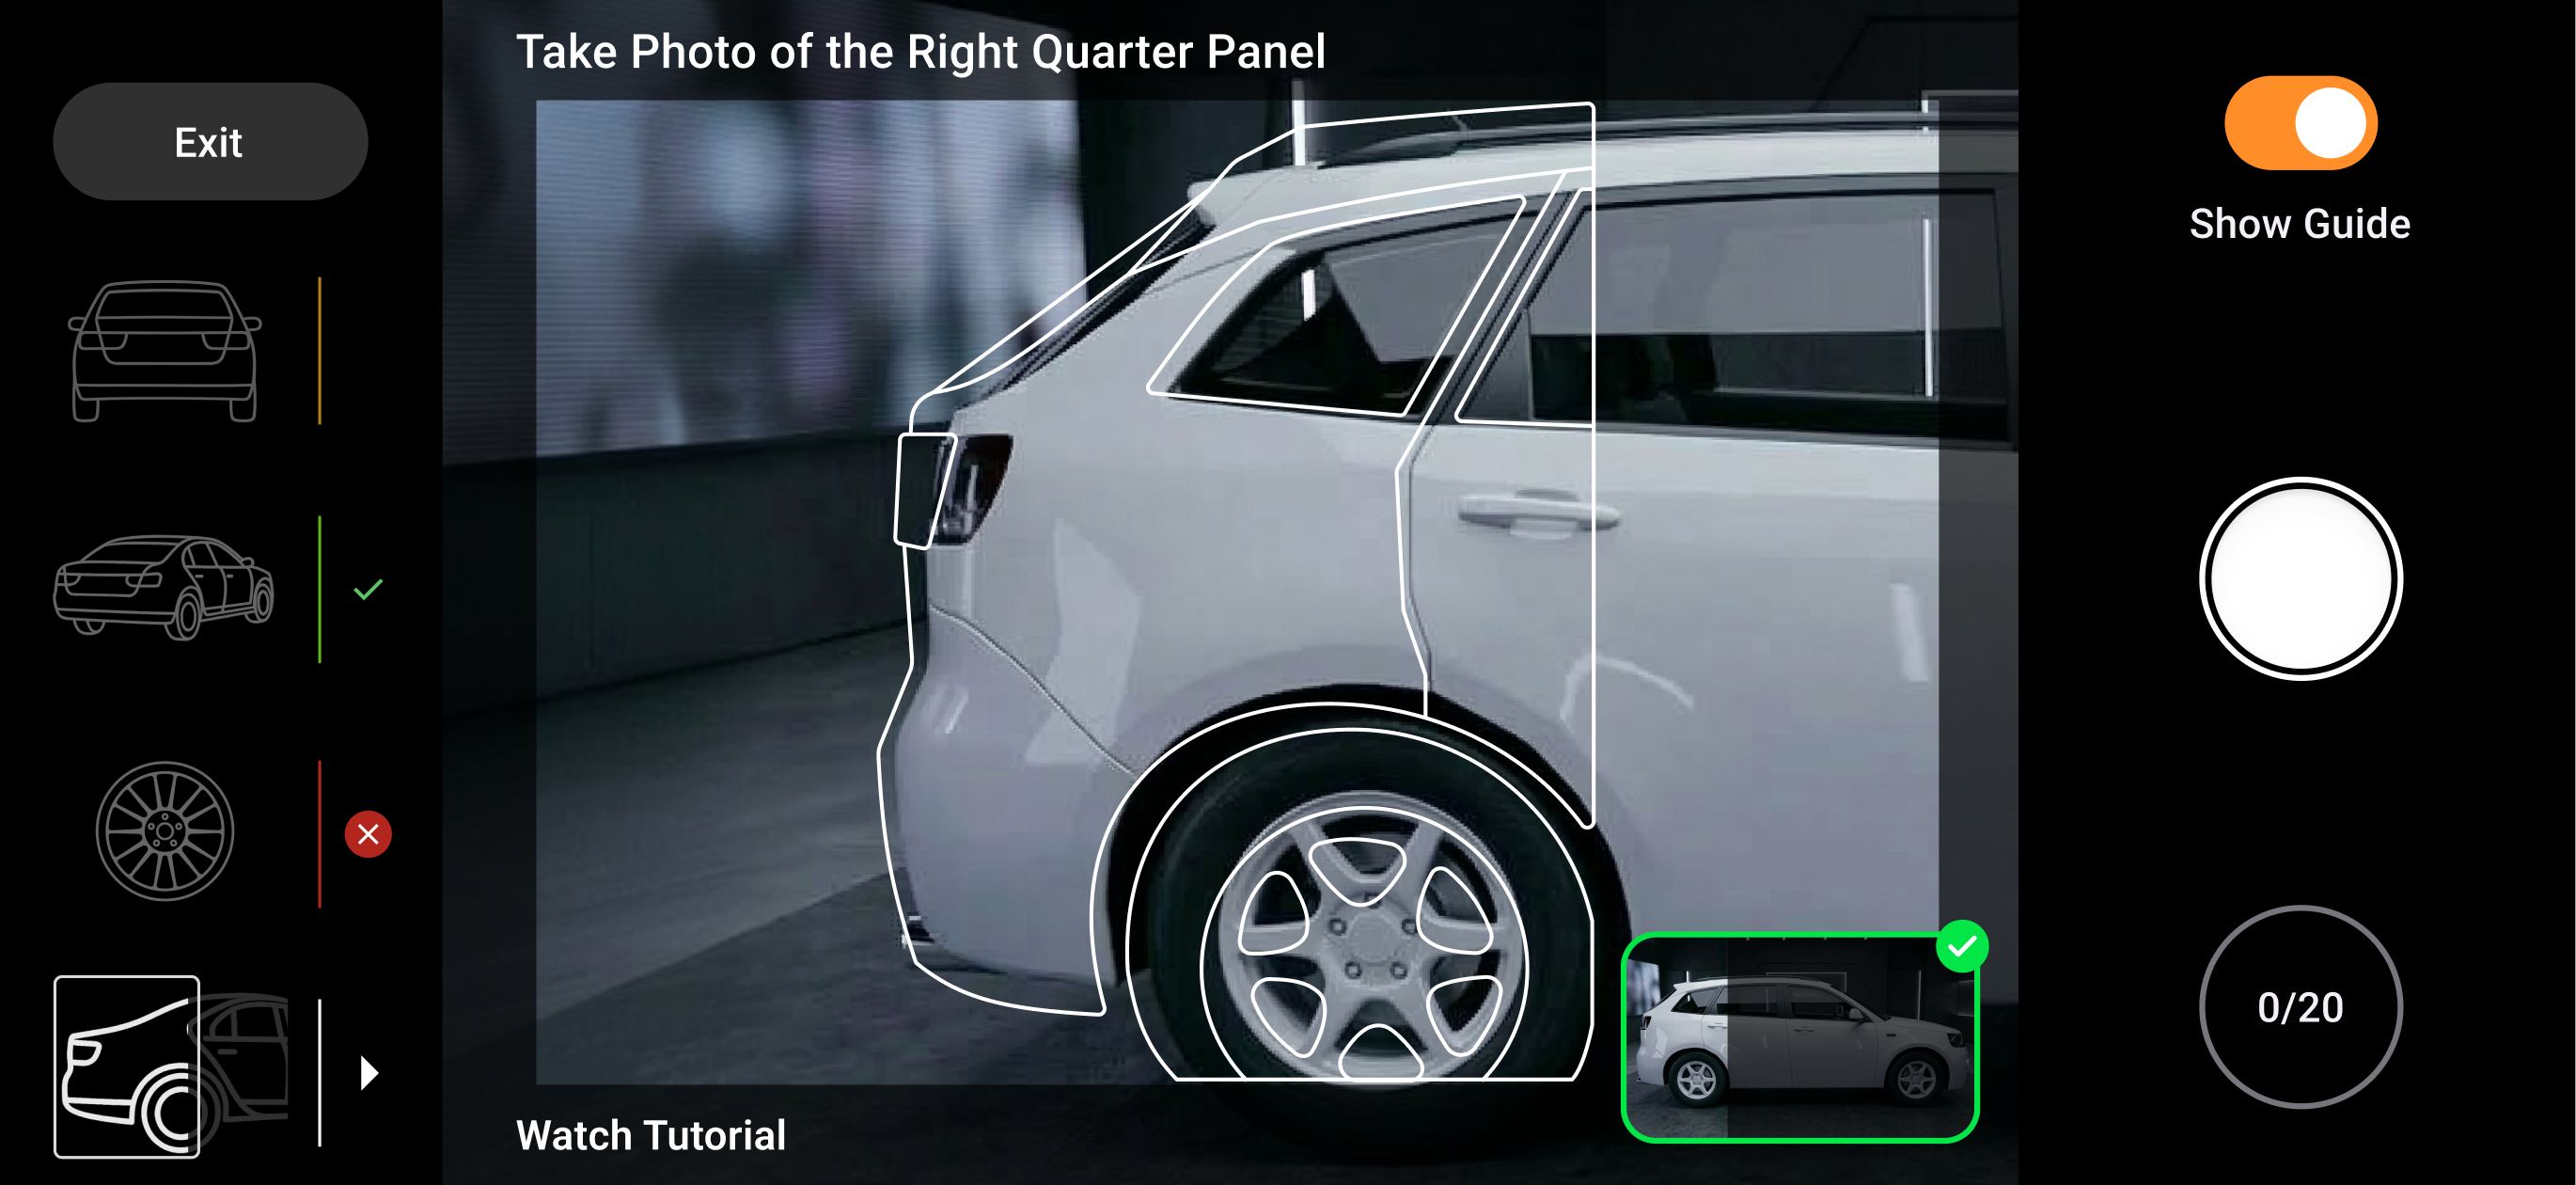
Different Capture Angles
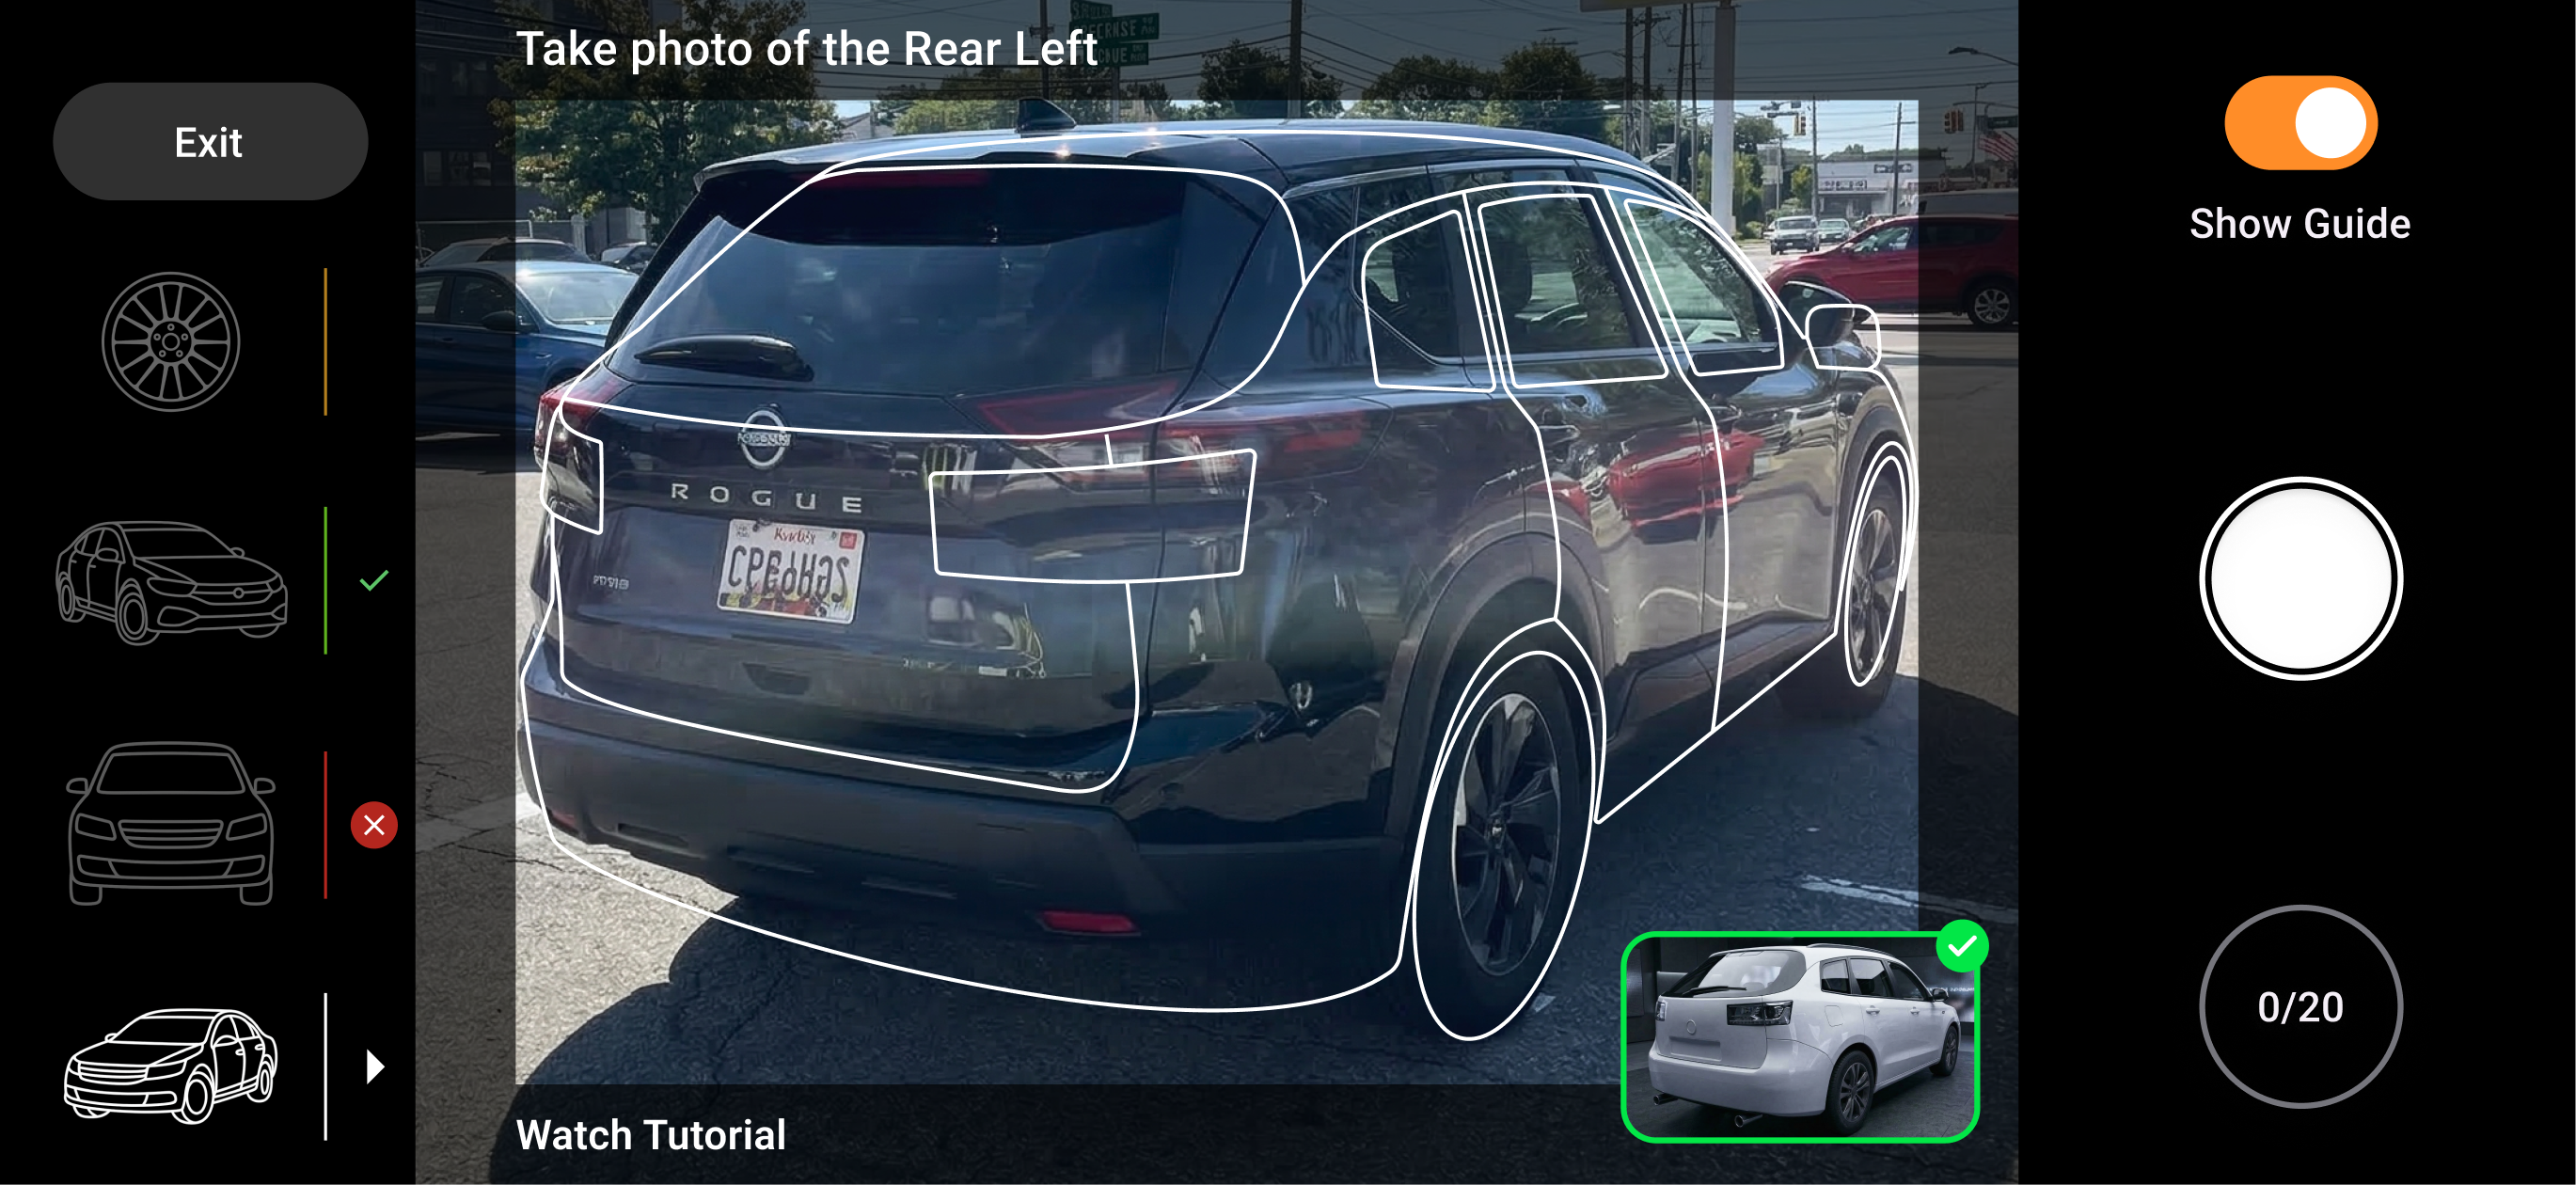
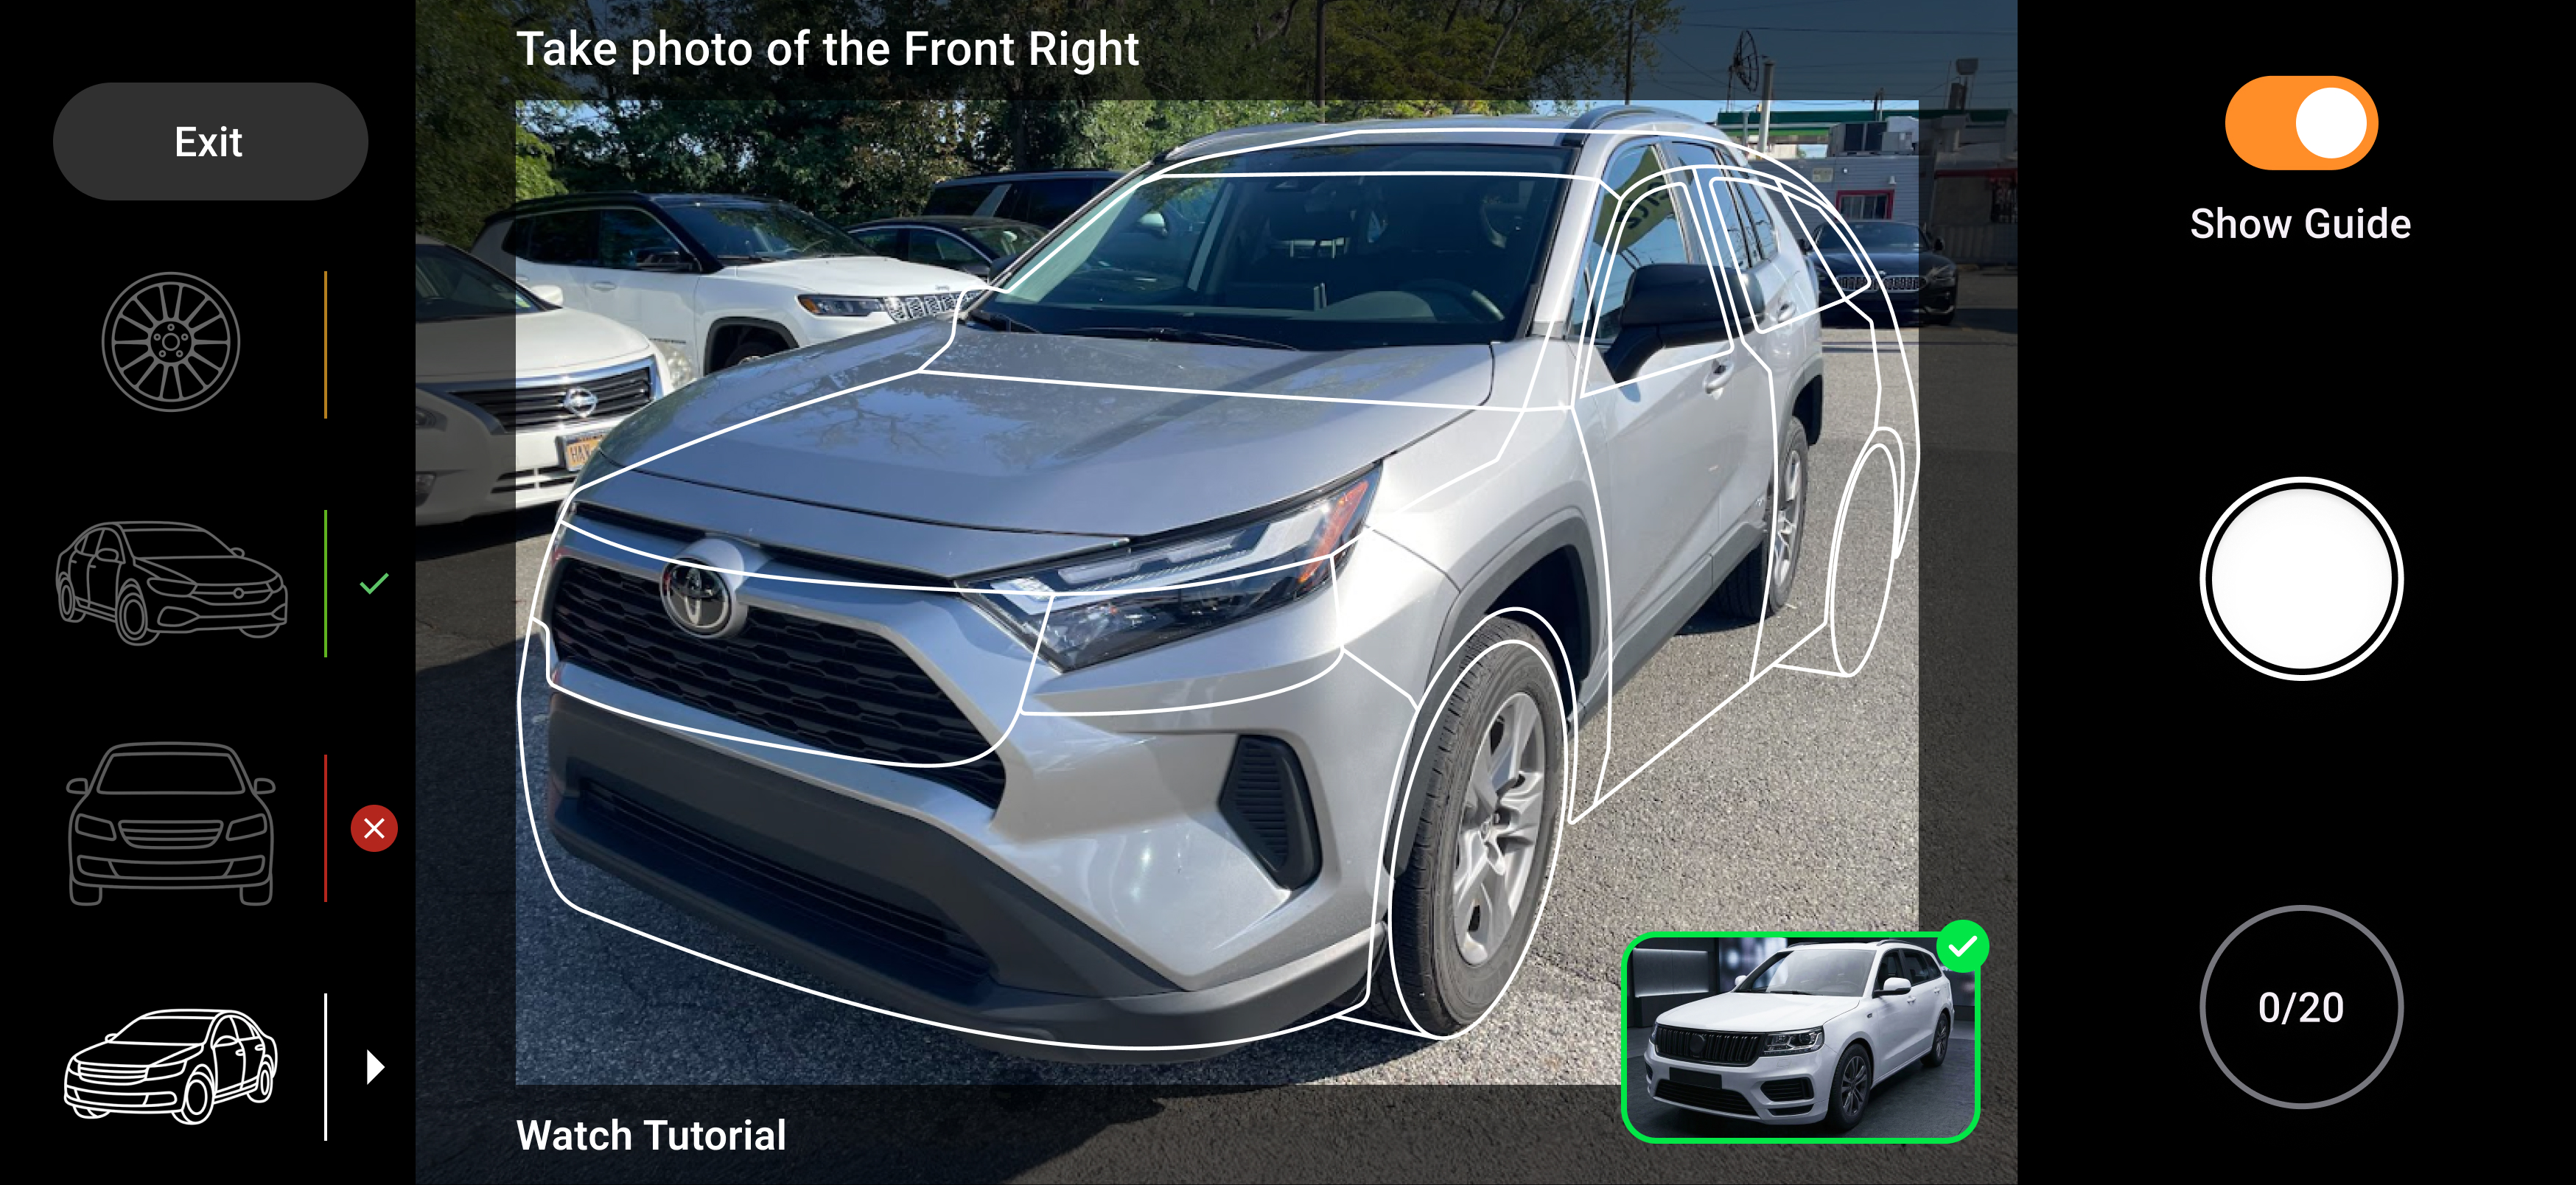
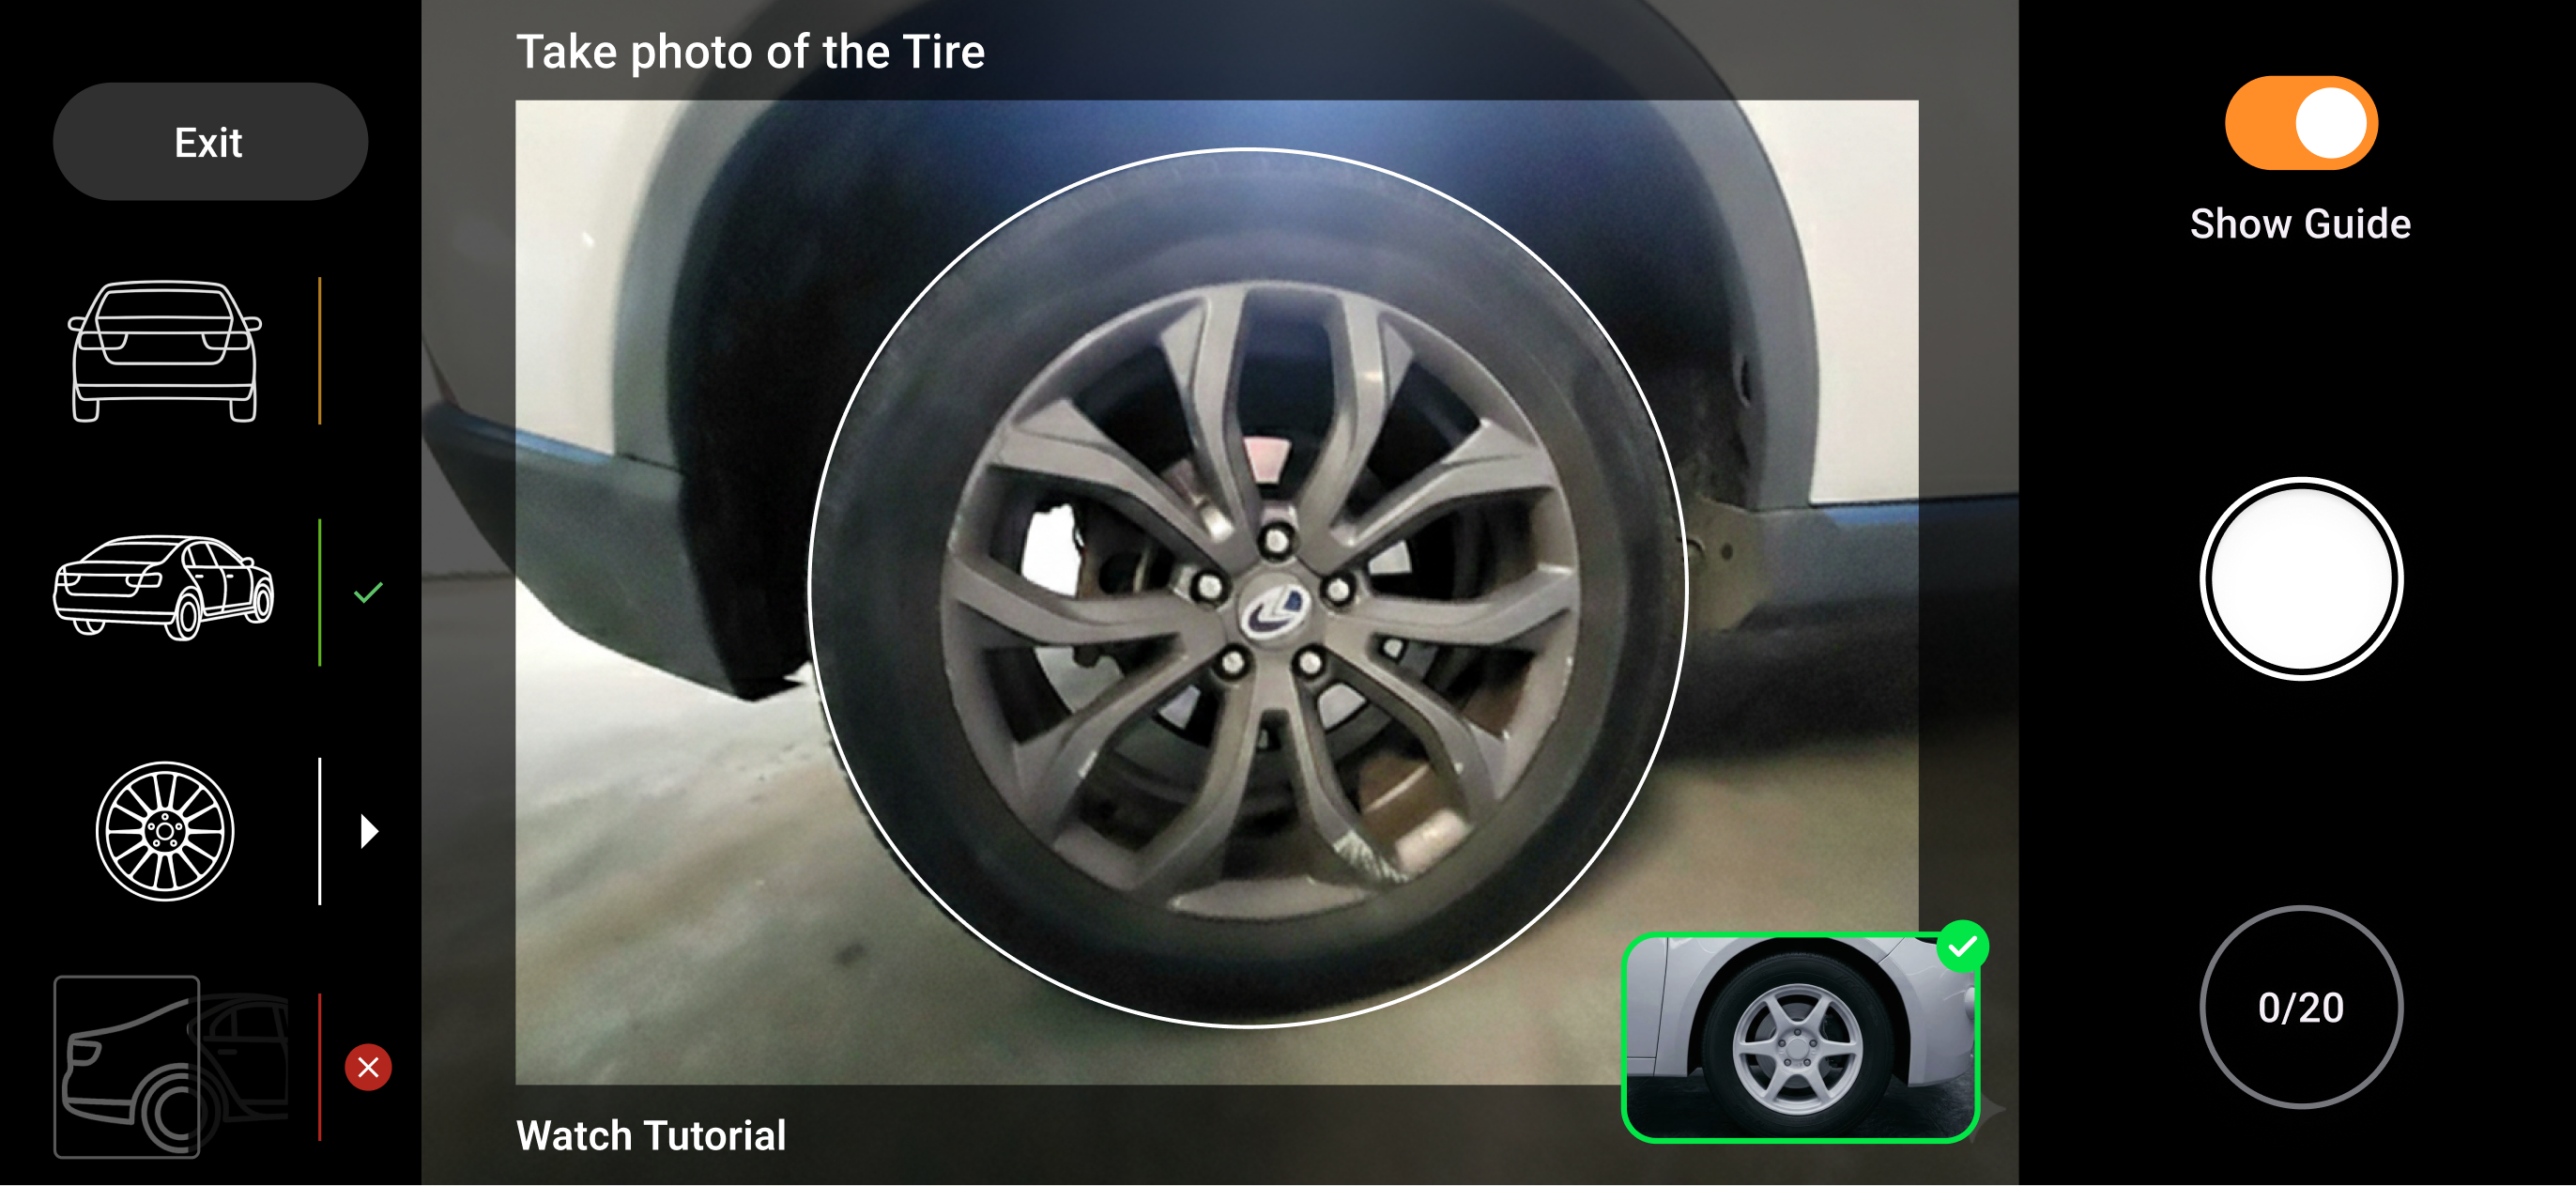
Before the first photo, a preparation prompt reminds agents to close the vehicle's doors and turn off its headlights. These simple actions are easy to overlook under time pressure but directly affect the quality and consistency of the captured images.
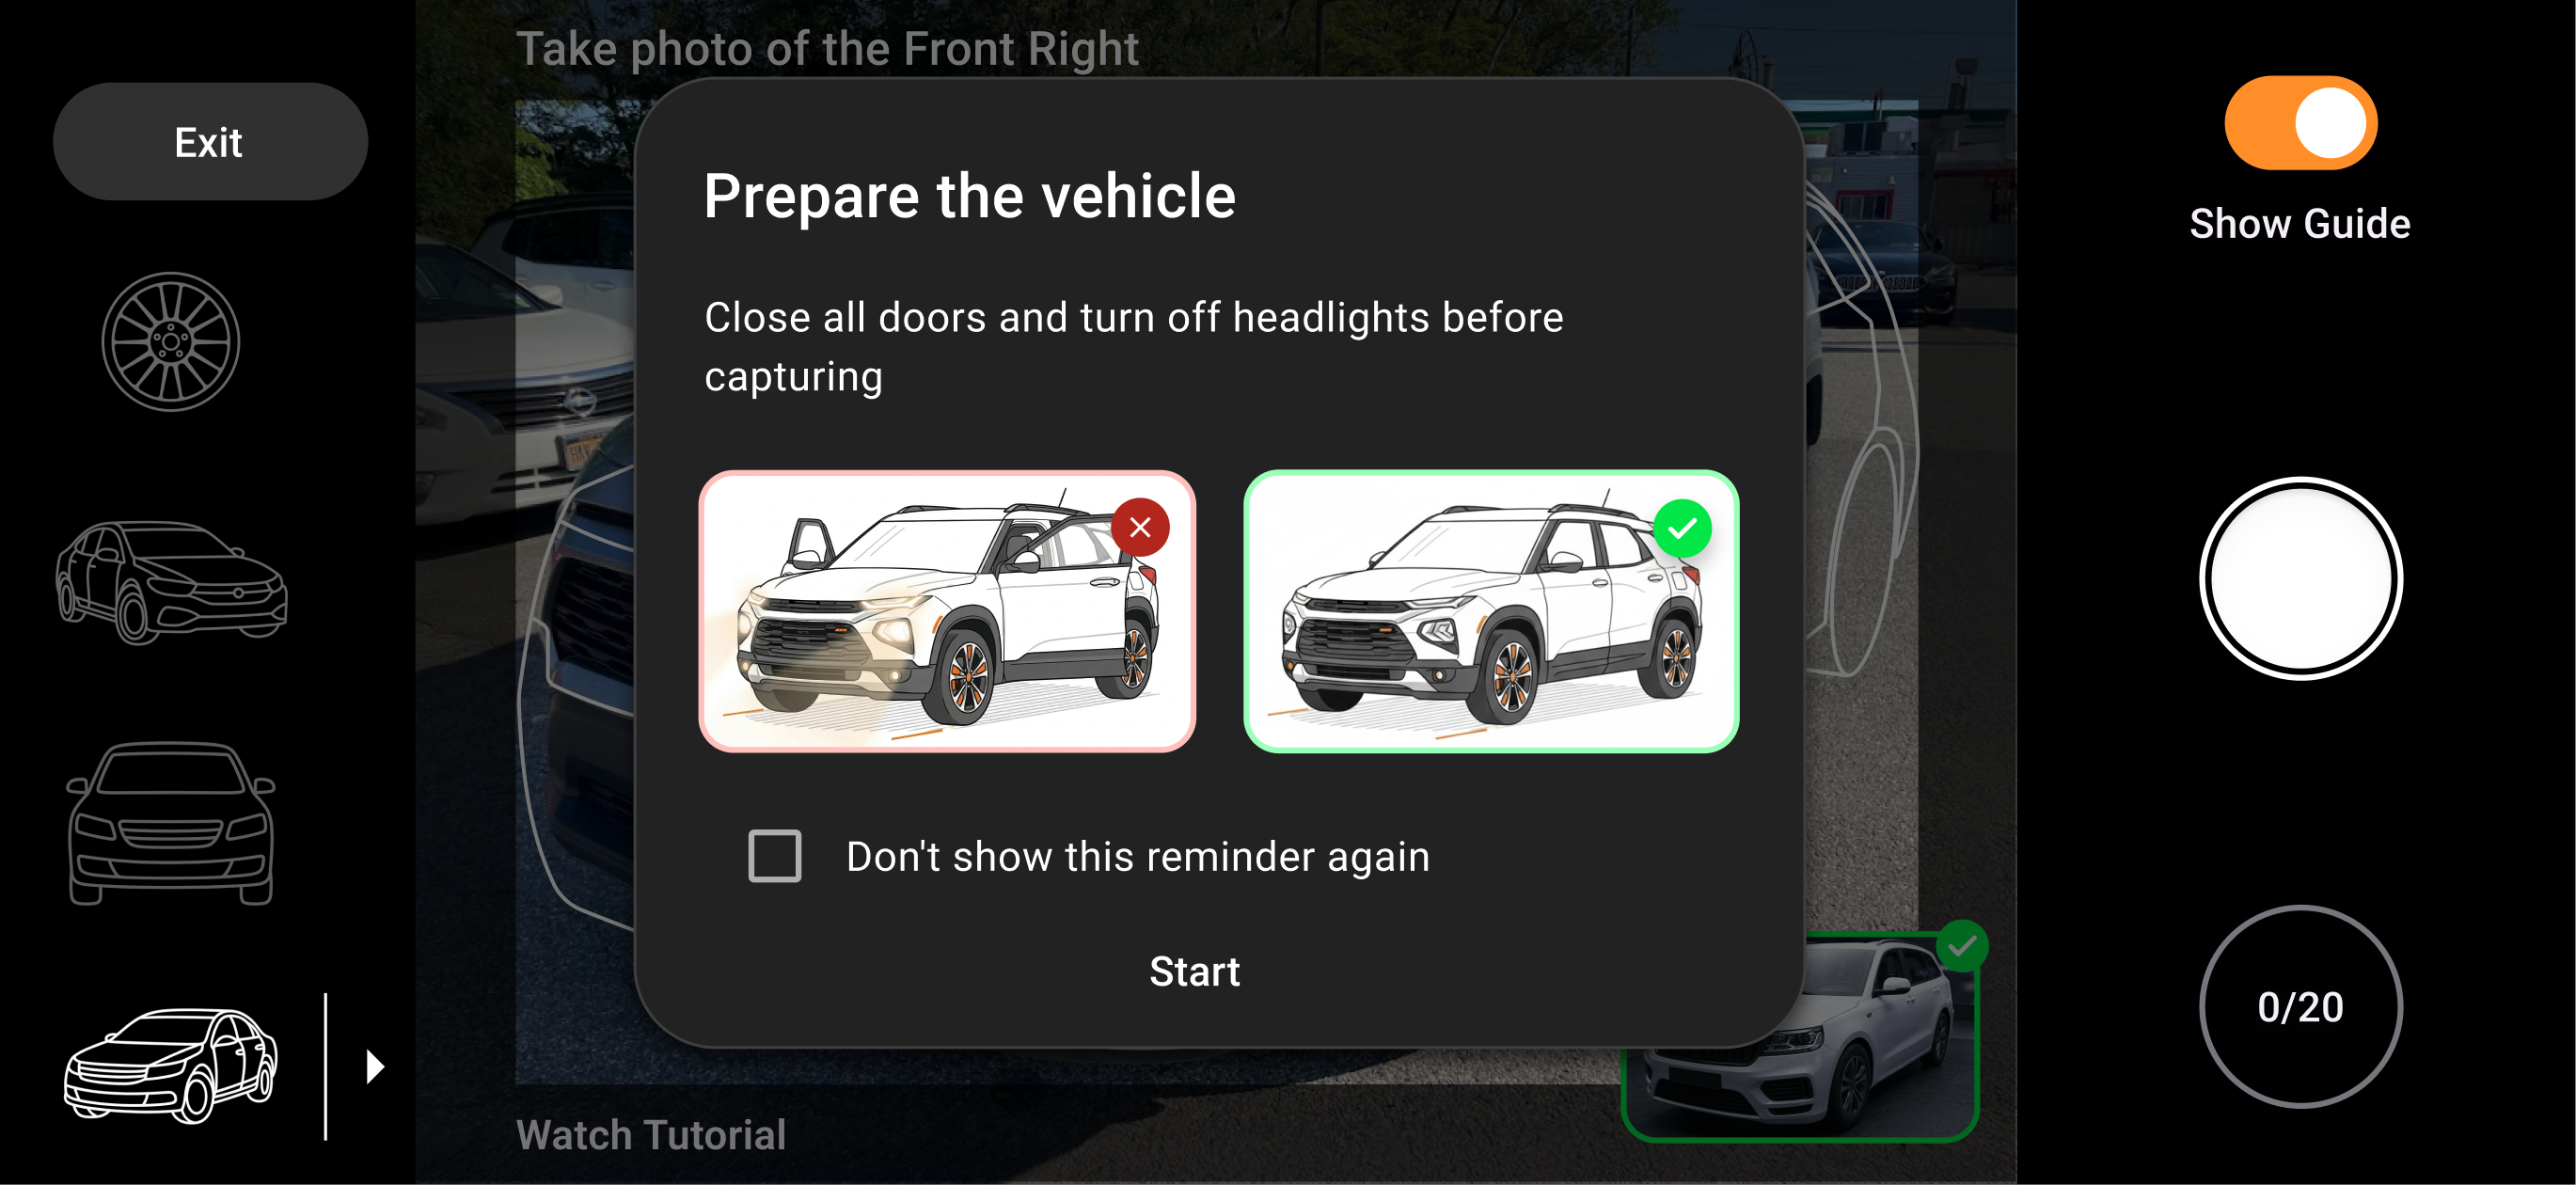
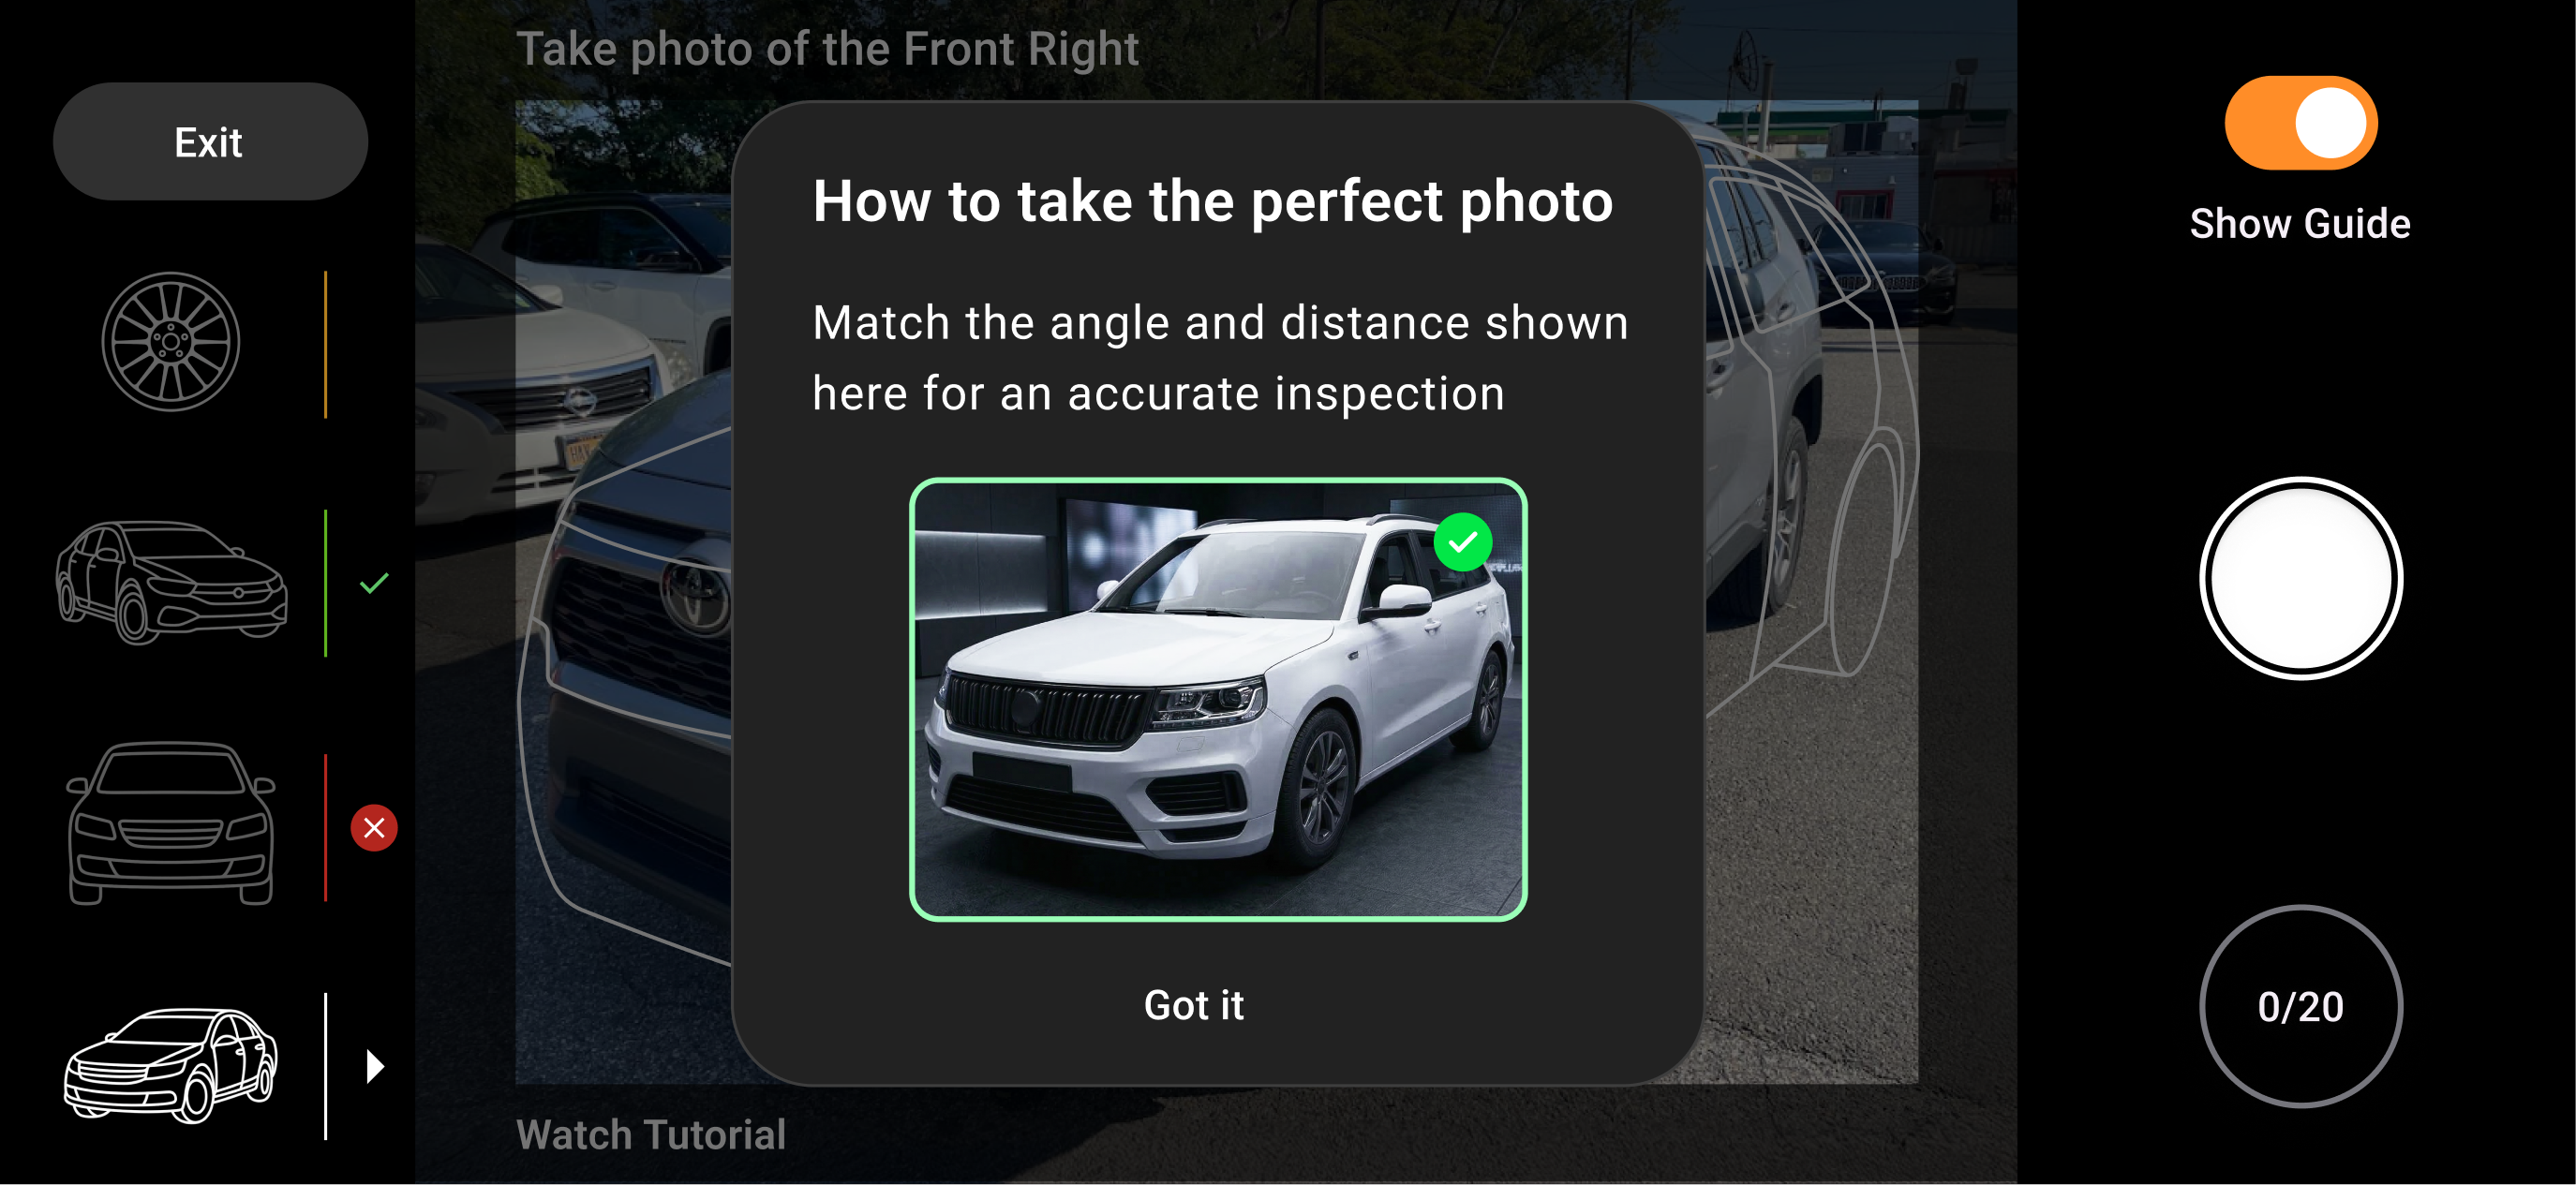
At the start of each new shot type, a reference card shows the required angle, vehicle area, and a successful example. Agents can see what they need to capture before raising the camera, then use the live overlay to align the shot.
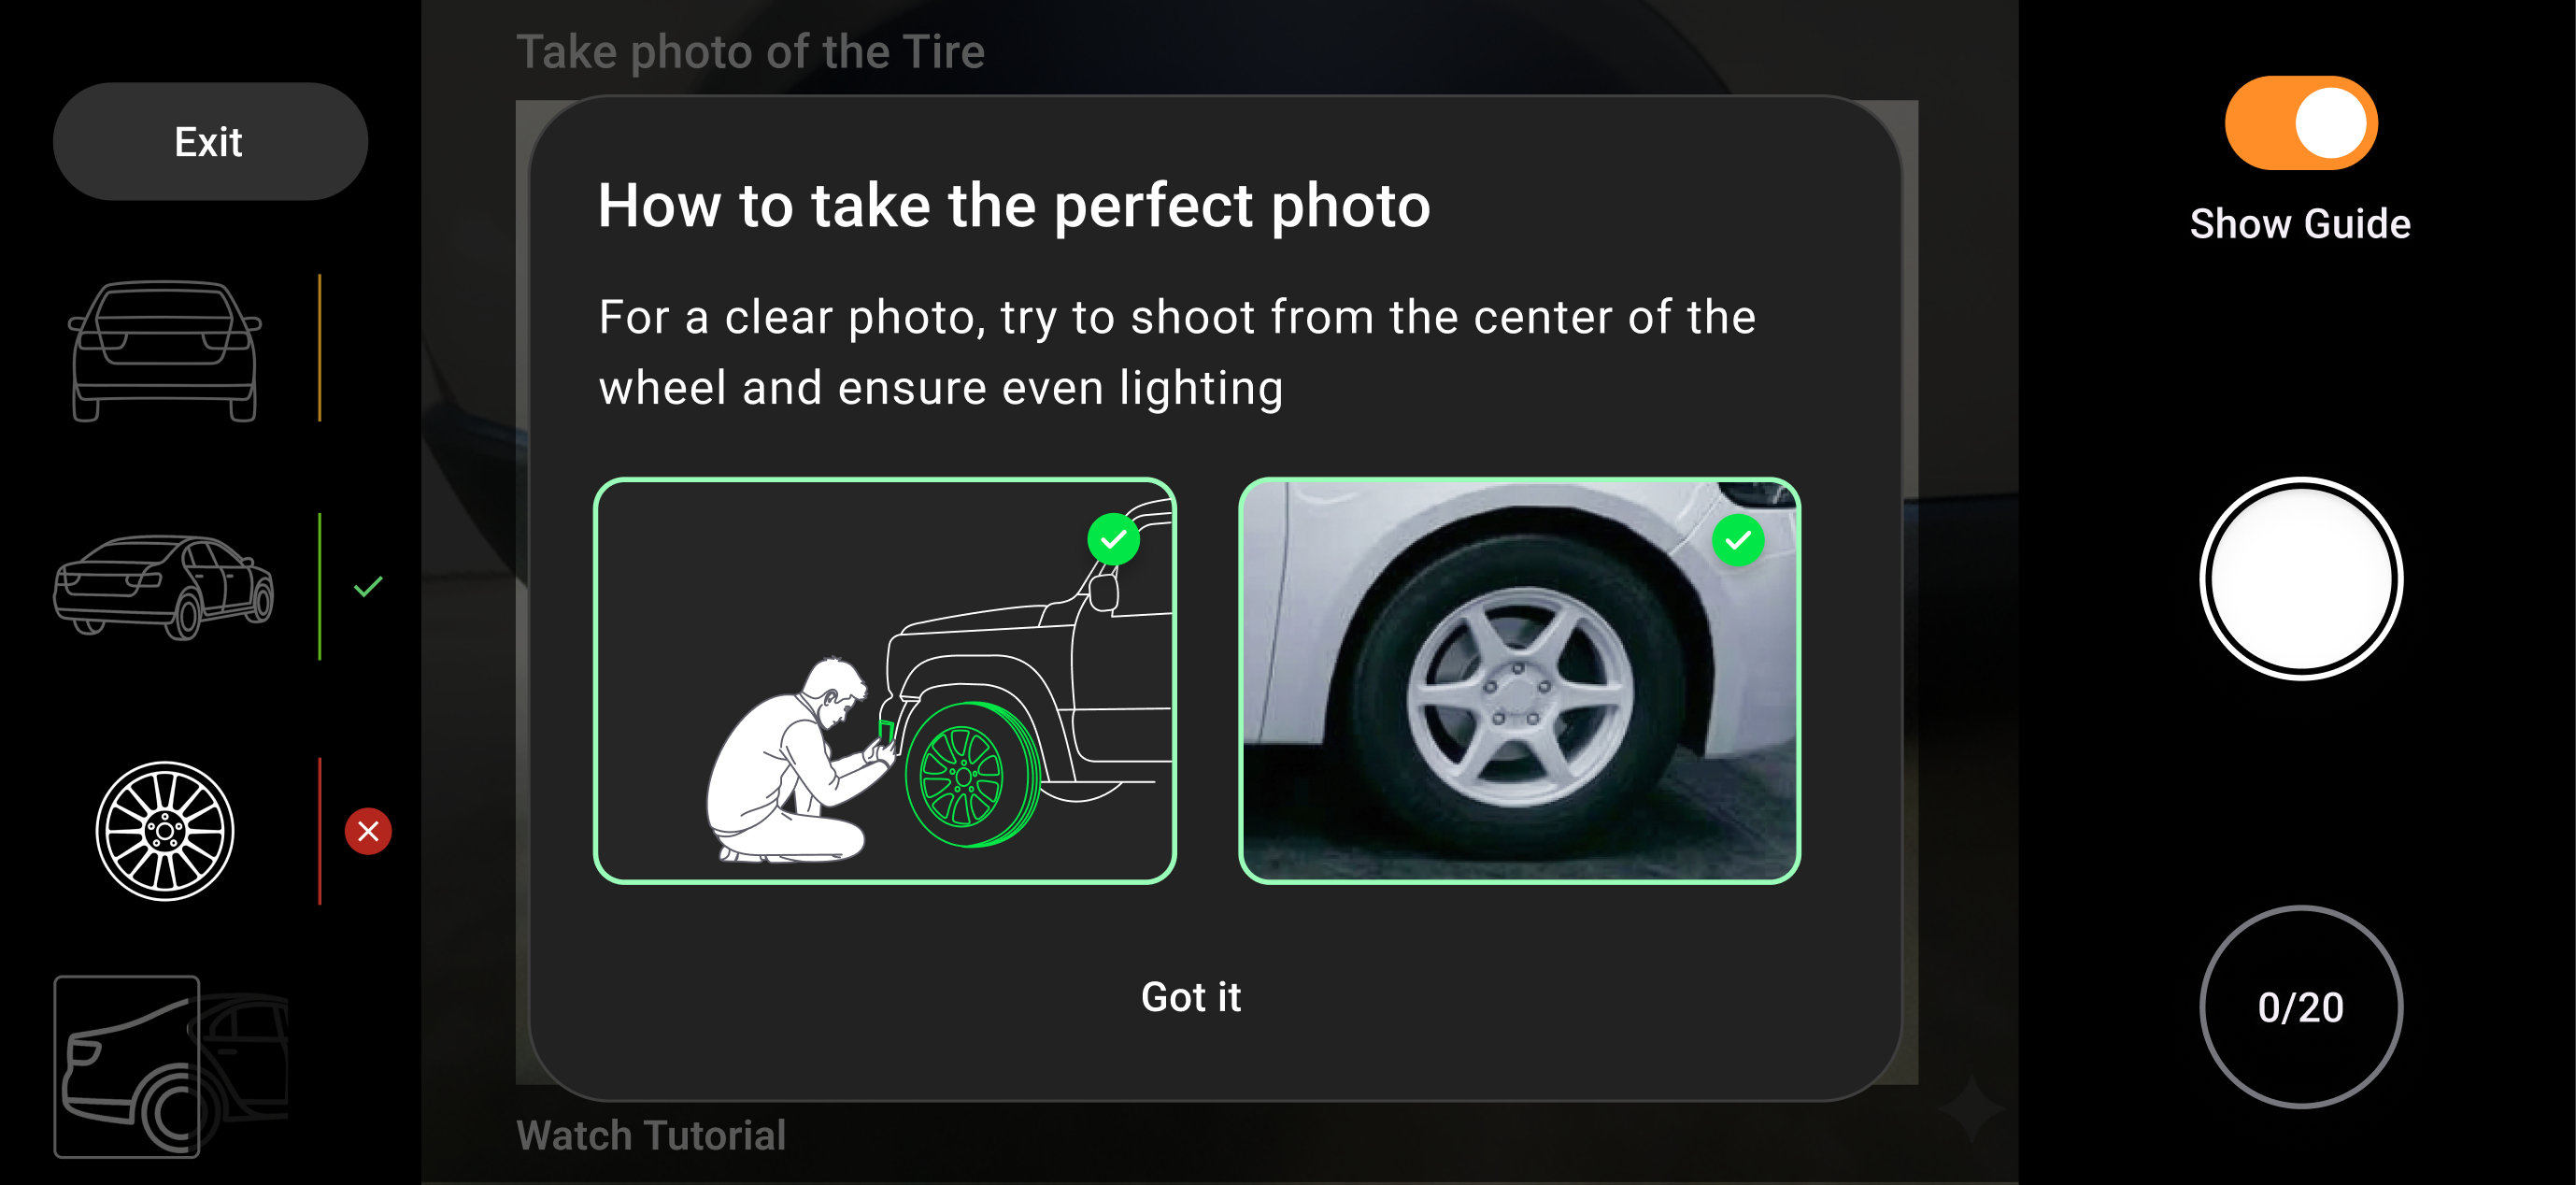
Tire photography required additional support because the correct position is less intuitive. An illustrated guide shows agents how to crouch at the center height of the wheel, helping them capture the angle required for reliable analysis.
Image validation could identify several common problems, but it could not always determine the exact reason a photo had failed. Blocking the inspection whenever confidence was low would leave agents trapped in a retry loop, even when the problem was caused by lighting, weather, or system limitations.
I designed a three-stage recovery flow that gradually increases support while keeping the inspection moving forward.
When the system can identify the problem with confidence, it explains what went wrong and recommends a specific correction.
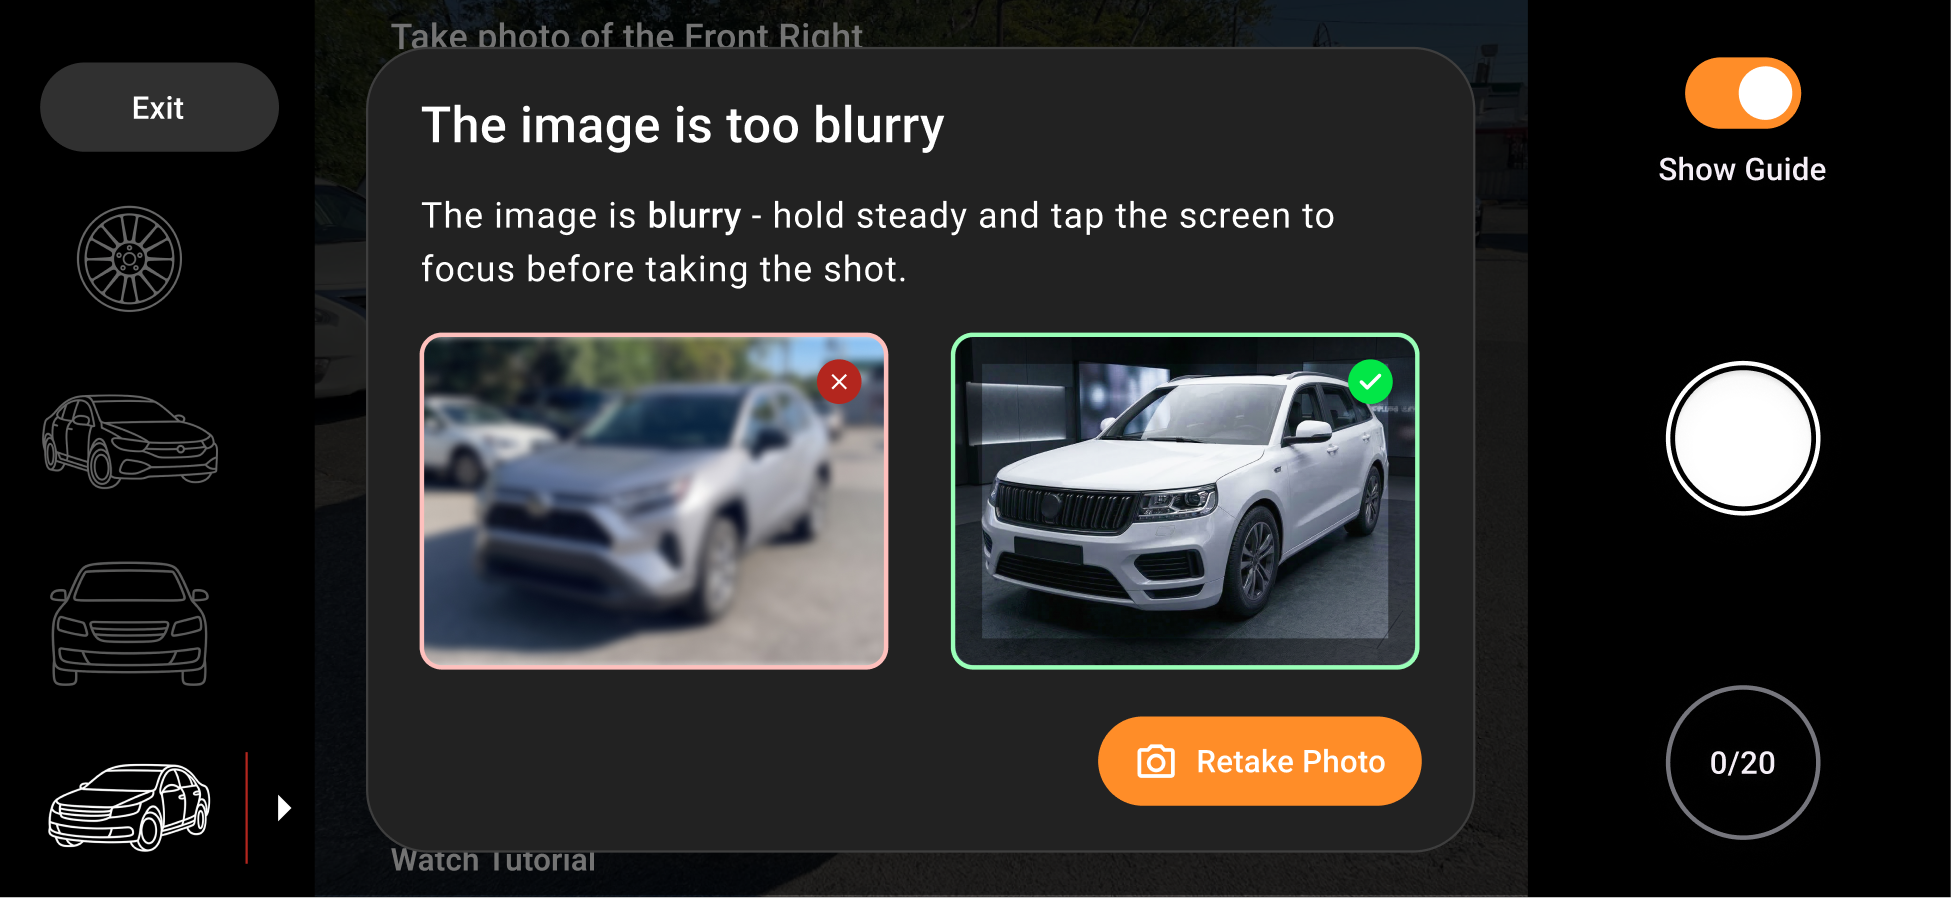
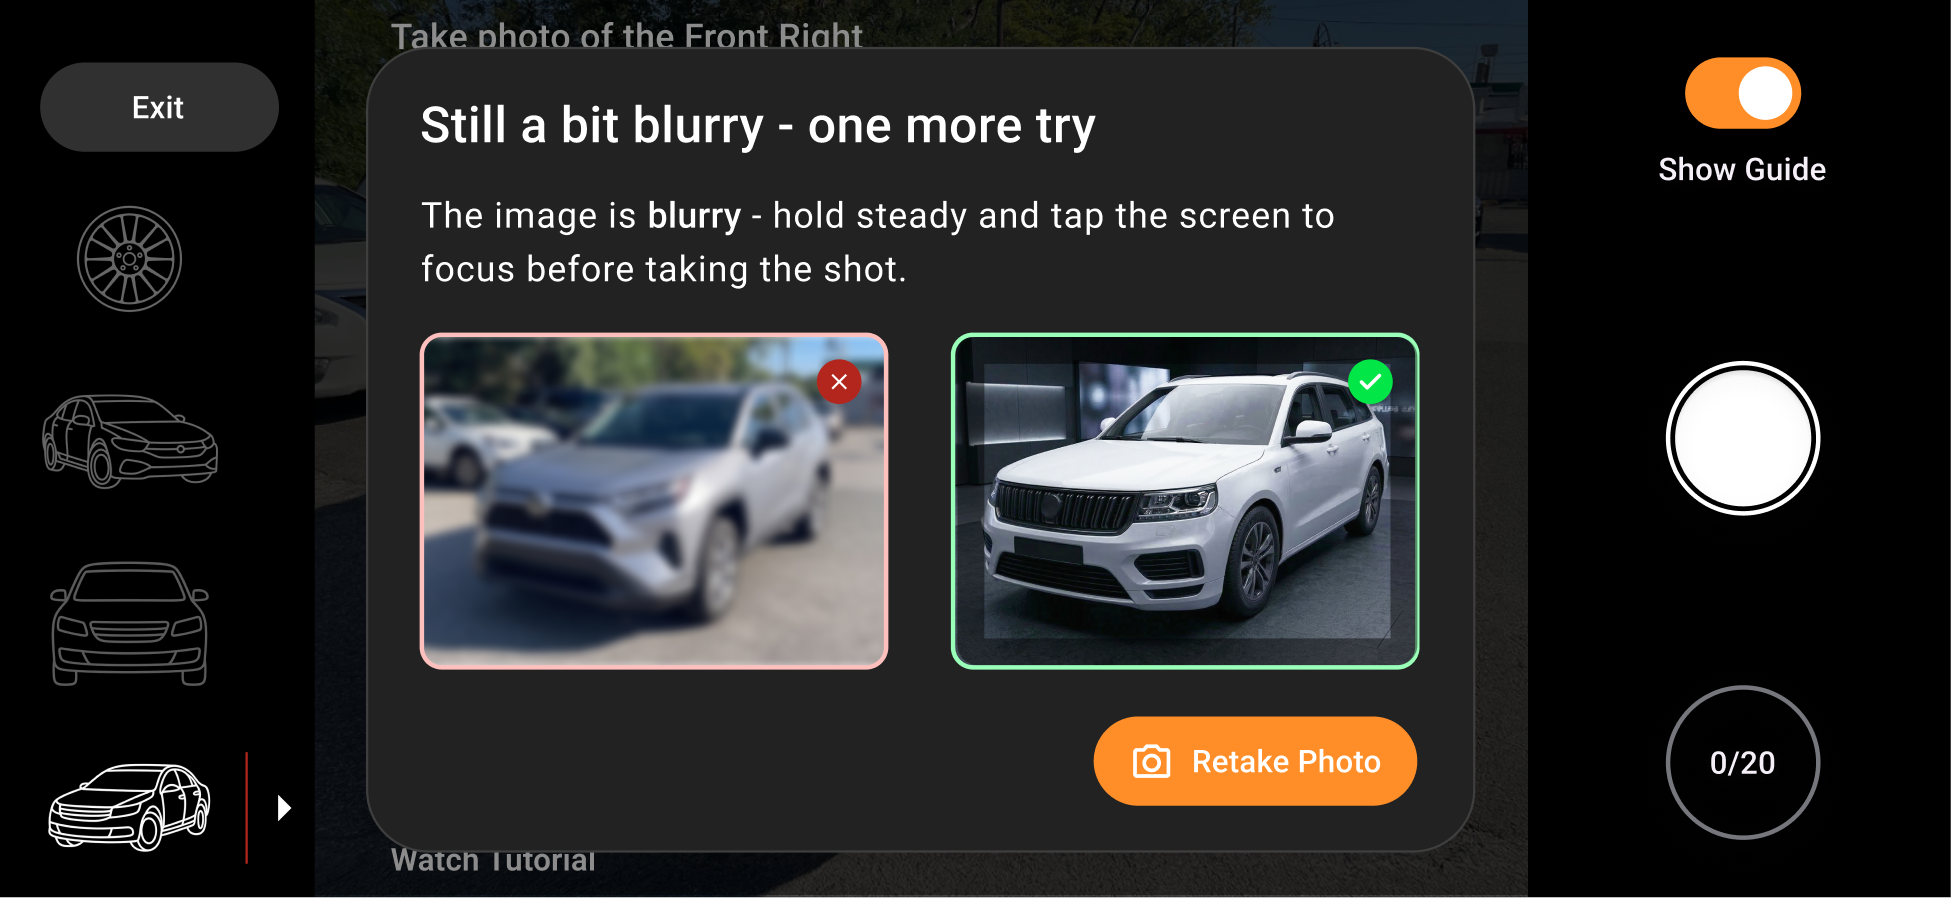
If the next attempt fails, the system strengthens the recommendation and encourages the agent to try again.
After three unsuccessful attempts, the agent can retake the photo or choose "Use Anyway." The image is accepted and can be flagged for downstream review rather than blocking the entire inspection.
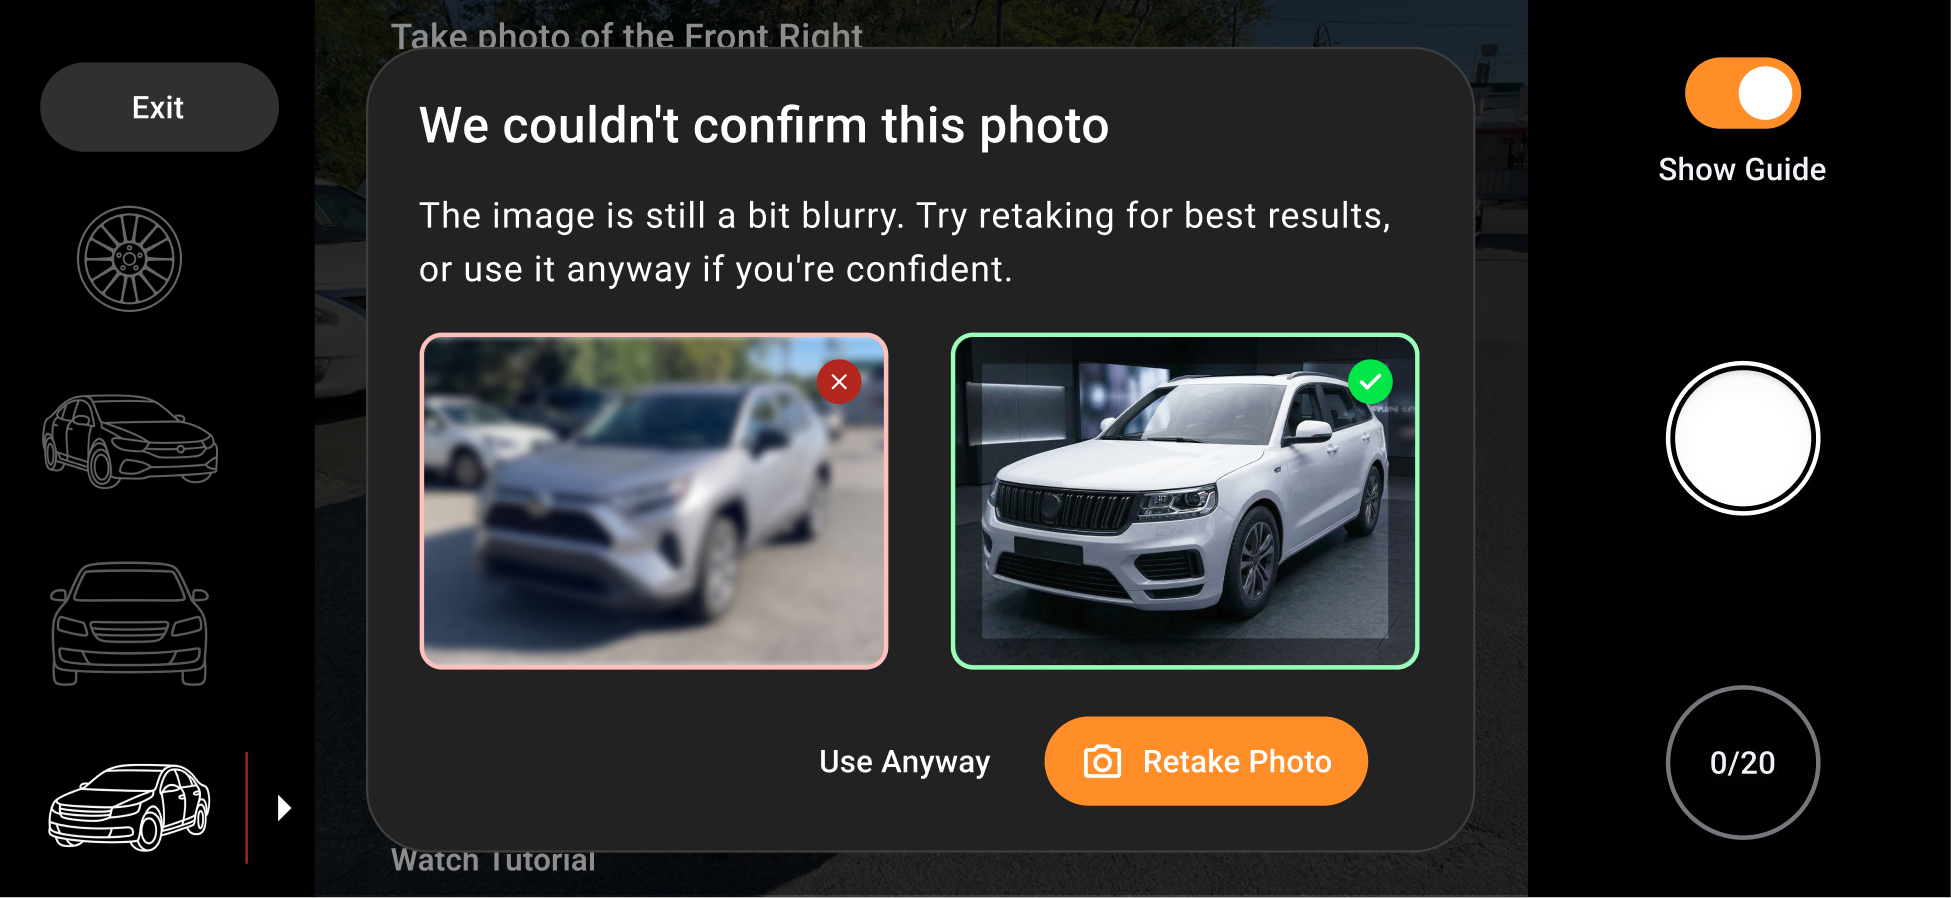
The final option was a deliberate product decision. After repeated failures, the cause may be the environment or the system rather than the agent. Allowing the inspection to continue respects the agent's judgment, preserves operational continuity, and avoids presenting uncertain AI feedback as fact.
The quality of the solution depended on resolving product, technical, and operational questions together, rather than passing completed designs between teams.
Together, we translated user and business needs into a focused product strategy, prioritized the problems that most affected adoption and completion, and defined which capabilities belonged in the first release.
I worked closely with the Data and Algorithms teams to understand the image coverage the system required, which quality problems it could identify reliably, and where its confidence ended. These constraints directly shaped the capture sequence, feedback language, and three-stage recovery flow.
I worked with Engineering to define interaction states and edge cases before implementation, including shared-device tutorial behavior, validation escalation, optional guidance controls, and animation behavior.
This collaboration kept design decisions technically grounded and made the system's capabilities and limitations visible in the experience.
Three tensions shaped the final experience. Each required balancing image quality and operational reliability with the realities of field use.
More guidance could prevent mistakes but also increase visual complexity. I used layered, contextual, and optional guidance so that support appeared when needed and could be reduced by experienced agents.
Strict validation could improve image quality but also prevent legitimate inspections from being completed. The three-stage recovery model maintained quality as the goal while preserving a path forward.
Specific feedback is useful only when the system can support it with confidence. When the cause of failure was uncertain, the experience acknowledged that uncertainty instead of presenting a plausible explanation as fact.
When the system could not be certain, the product should not pretend otherwise.
HLE provided a practical mobile inspection workflow for rental locations where UVeye's fixed scanning systems could not be installed. The redesigned experience was launched across multiple sites, extending structured vehicle documentation to locations without permanent inspection infrastructure.
Following the redesign, we observed a clear upward trend in product usage and received positive field feedback about the clarity of the workflow and capture guidance.
Agents who had previously struggled with the process, or abandoned it before completion, were better able to understand the required sequence, capture the necessary images, and complete the inspection.
The redesigned experience also reduced dependence on one-time, in-person training. Guidance remained available inside the product across changing shifts, shared devices, and new staff onboarding.
The result was a more consistent, usable, and operationally sustainable mobile inspection process for sites that could not support a permanent scanning system.
The most important design decision happened before any interface was created. Reframing the challenge from a photo-quality problem to an uncertainty problem changed the direction of the entire solution.
The final experience had to coordinate a 20-photo sequence, technical image requirements, visual guidance, validation, error recovery, shared-device behavior, and the limits of AI. The agent, however, needed to see only the next clear action.
Designing around the system's limitations rather than hiding them produced a more honest and resilient product. When the AI could not explain a failure with confidence, the experience acknowledged that uncertainty and preserved a path forward.
Simplicity for the user requires the design to carry the complexity.